Output
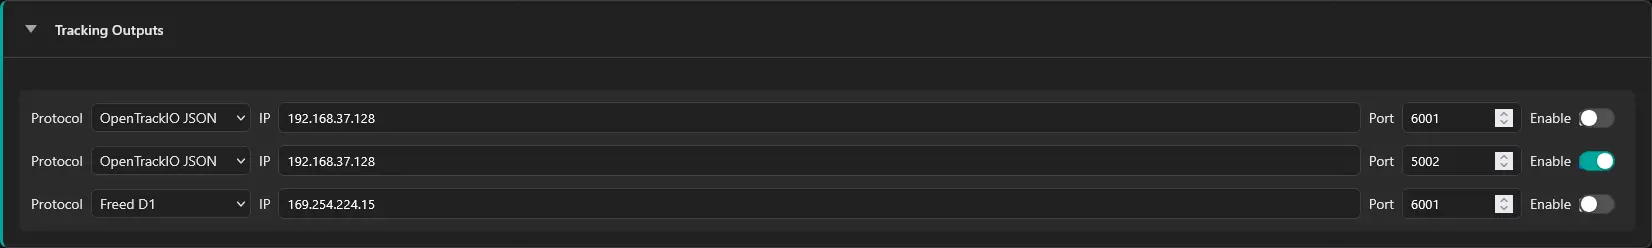
RigFX can send tracking data to up to 3 destinations simultaneously. Each destination picks its own protocol, IP, and port.
Protocols
You can send camera tracking data as:
- FreeD6 D1 — legacy binary UDP: pose plus the raw zoom and focus encoder values.
- OpenTrackIO11 — modern JSON: pose plus the full resolved lens (focal length, focus distance, distortion…).
Both are UDP-over-Ethernet protocols. Which one to pick depends on where your lens file lives: see Reference → Lens pipeline & outputs.
Per-destination fields
- Protocol — FreeD6 or OpenTrackIO11. The options link under it opens that protocol's options (below).
- IP — IP address to send the camera tracking data to. Usually the render-engine computer.
- Port — UDP port on the target computer to send the data to.
- Enable — toggles the data stream on/off.
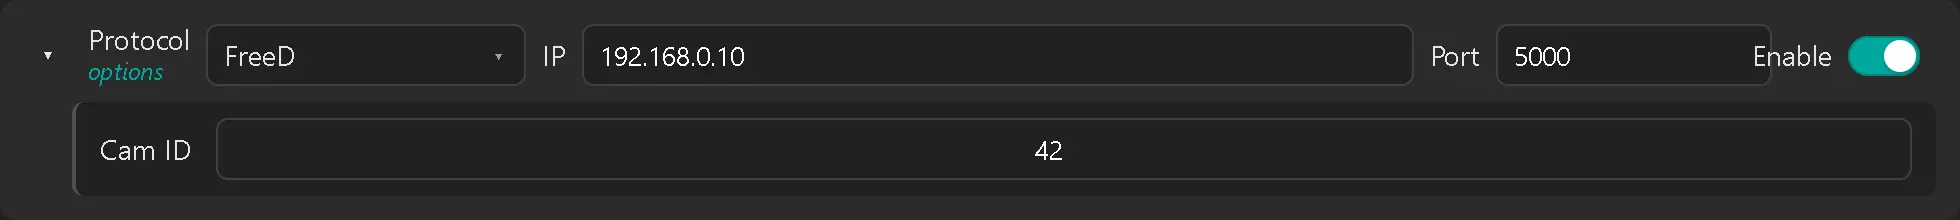
FreeD options
| Option | What it does |
|---|---|
| Cam ID | The camera ID written into every FreeD packet (0–255). Set it when the render engine receives several cameras on one port and tells them apart by ID. |
OpenTrackIO options
^ options of the first output open](../../assets/screenshots/output_opentrackio_options.webp)
The options are grouped by the receiver they are made for; leave them off for any other receiver.
| Option | Receiver | What it does |
|---|---|---|
| Chain transforms | CalibFX Lineup | Sends each node of the rig as its own transform (Studio offset17, every node, Sensor offset15) instead of the single combined camera pose, so Lineup can solve the studio and sensor offsets. |
| Invert Cx | Aximmetry | Flips the sign of the horizontal projection offset (the lens centre shift, Cx), as Aximmetry expects it. |
| Legacy distortion order | Aximmetry 2025.3.0 or earlier | Sends the radial distortion coefficients in the order those Aximmetry versions read them. |
Each output has its own options: you can send the same data to Aximmetry on one output and to CalibFX Lineup on another.