Cartoni e-Jibo + Sony FR7 underslung
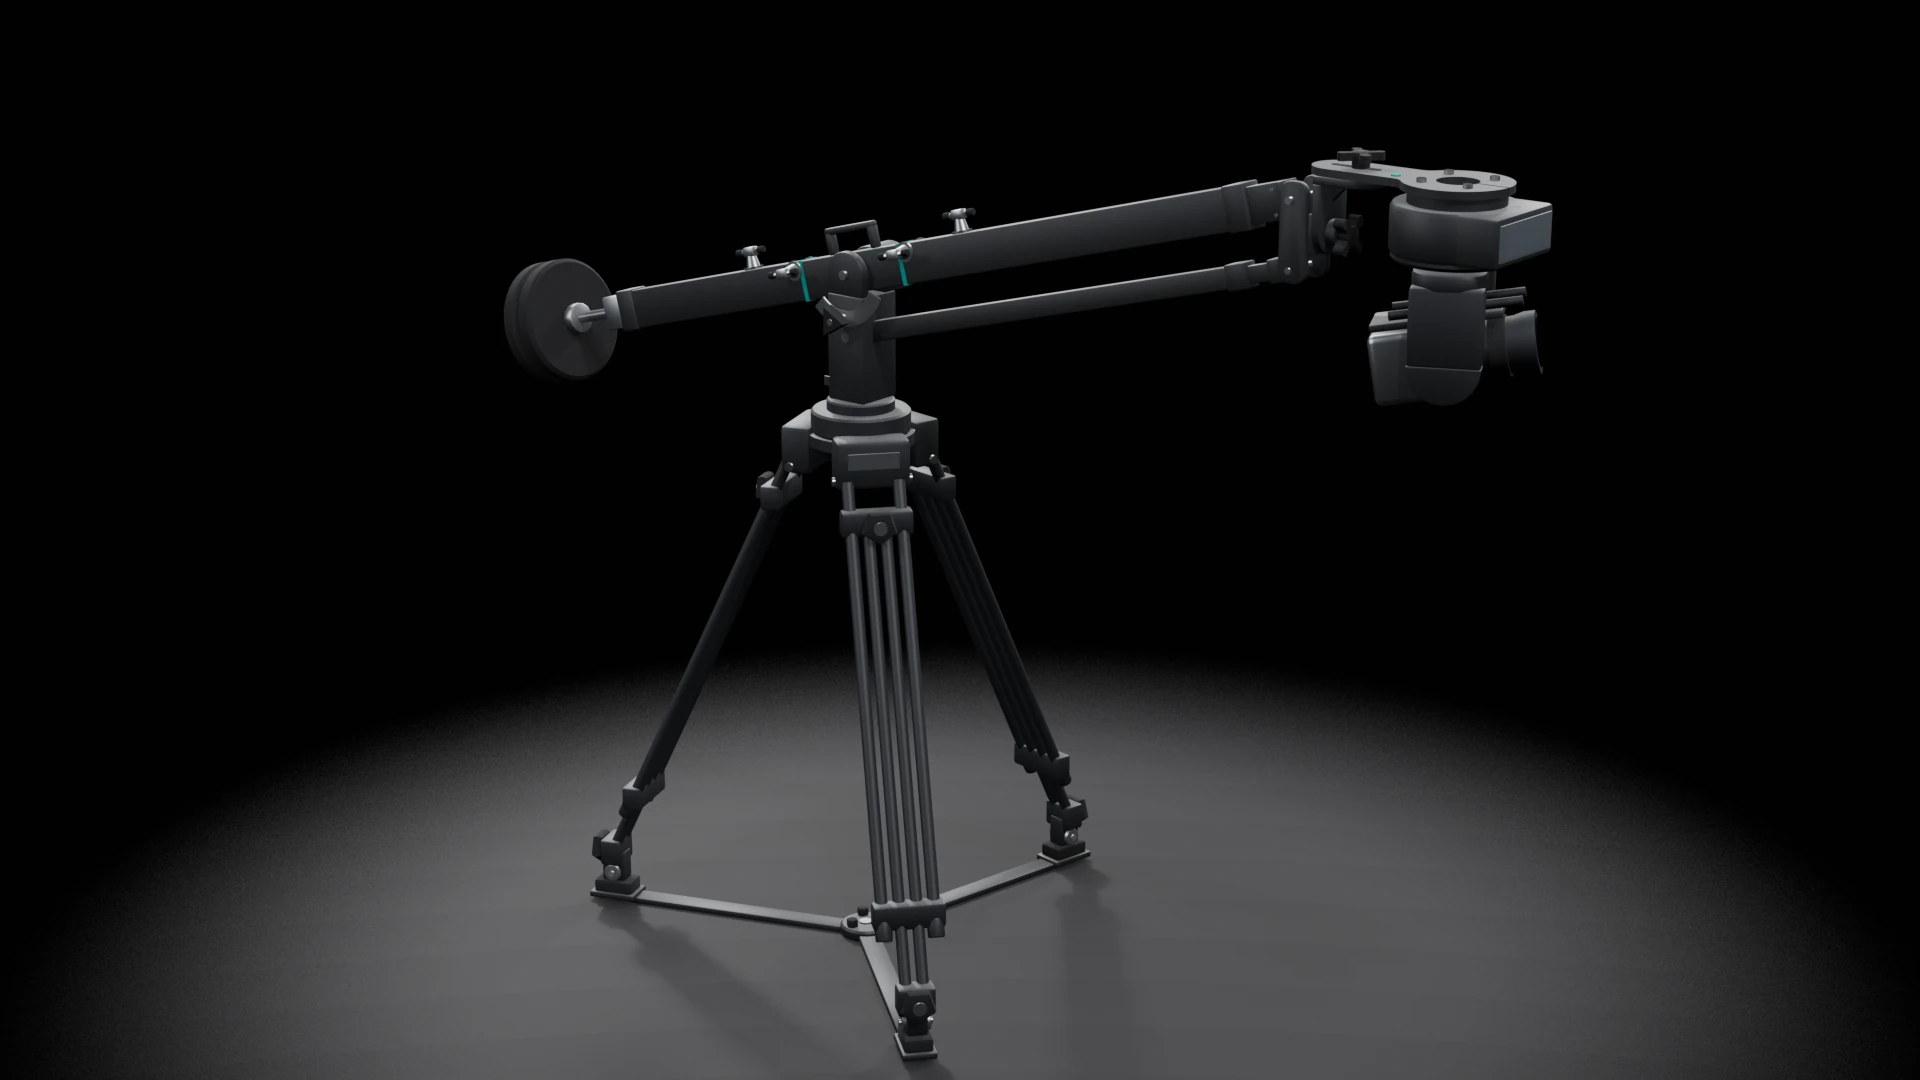
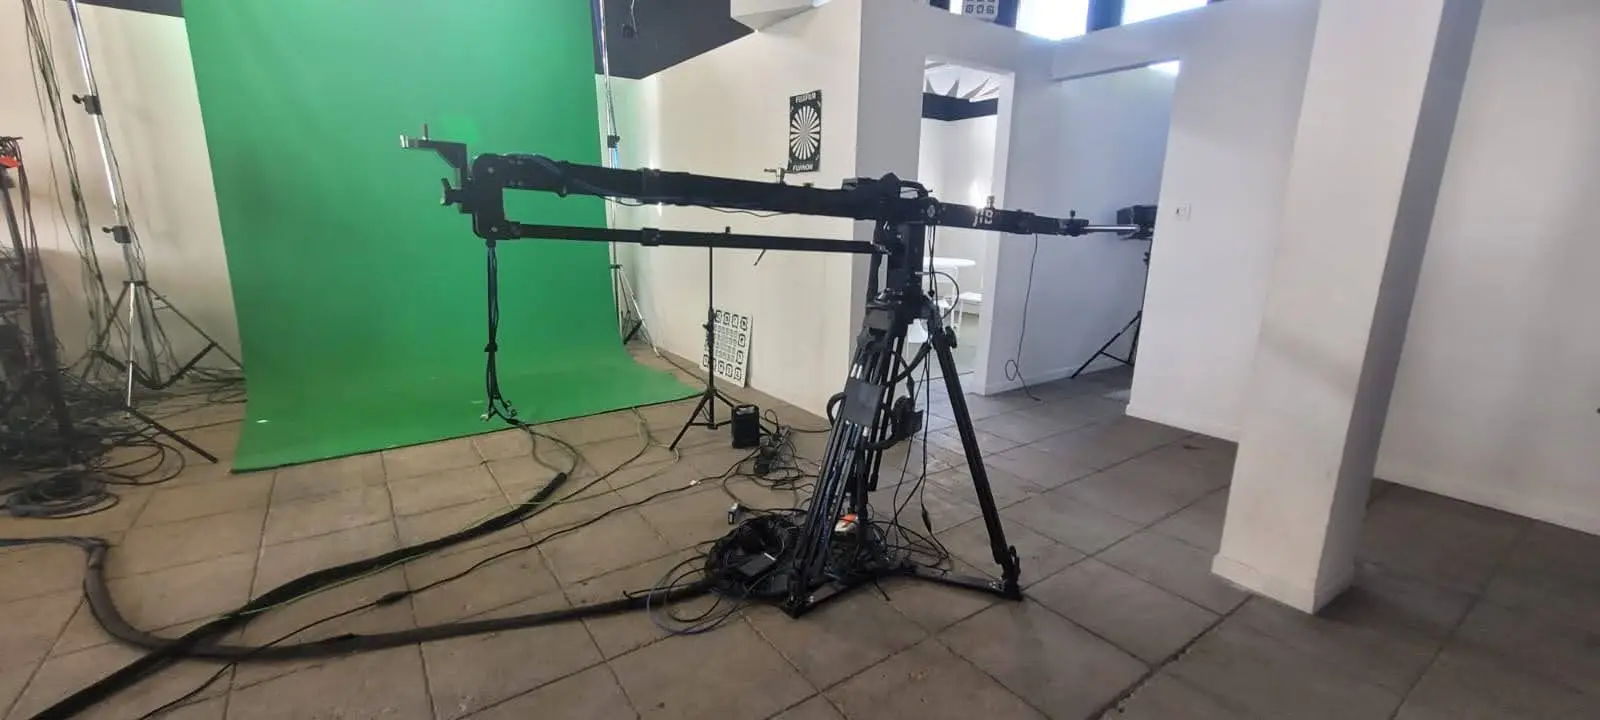
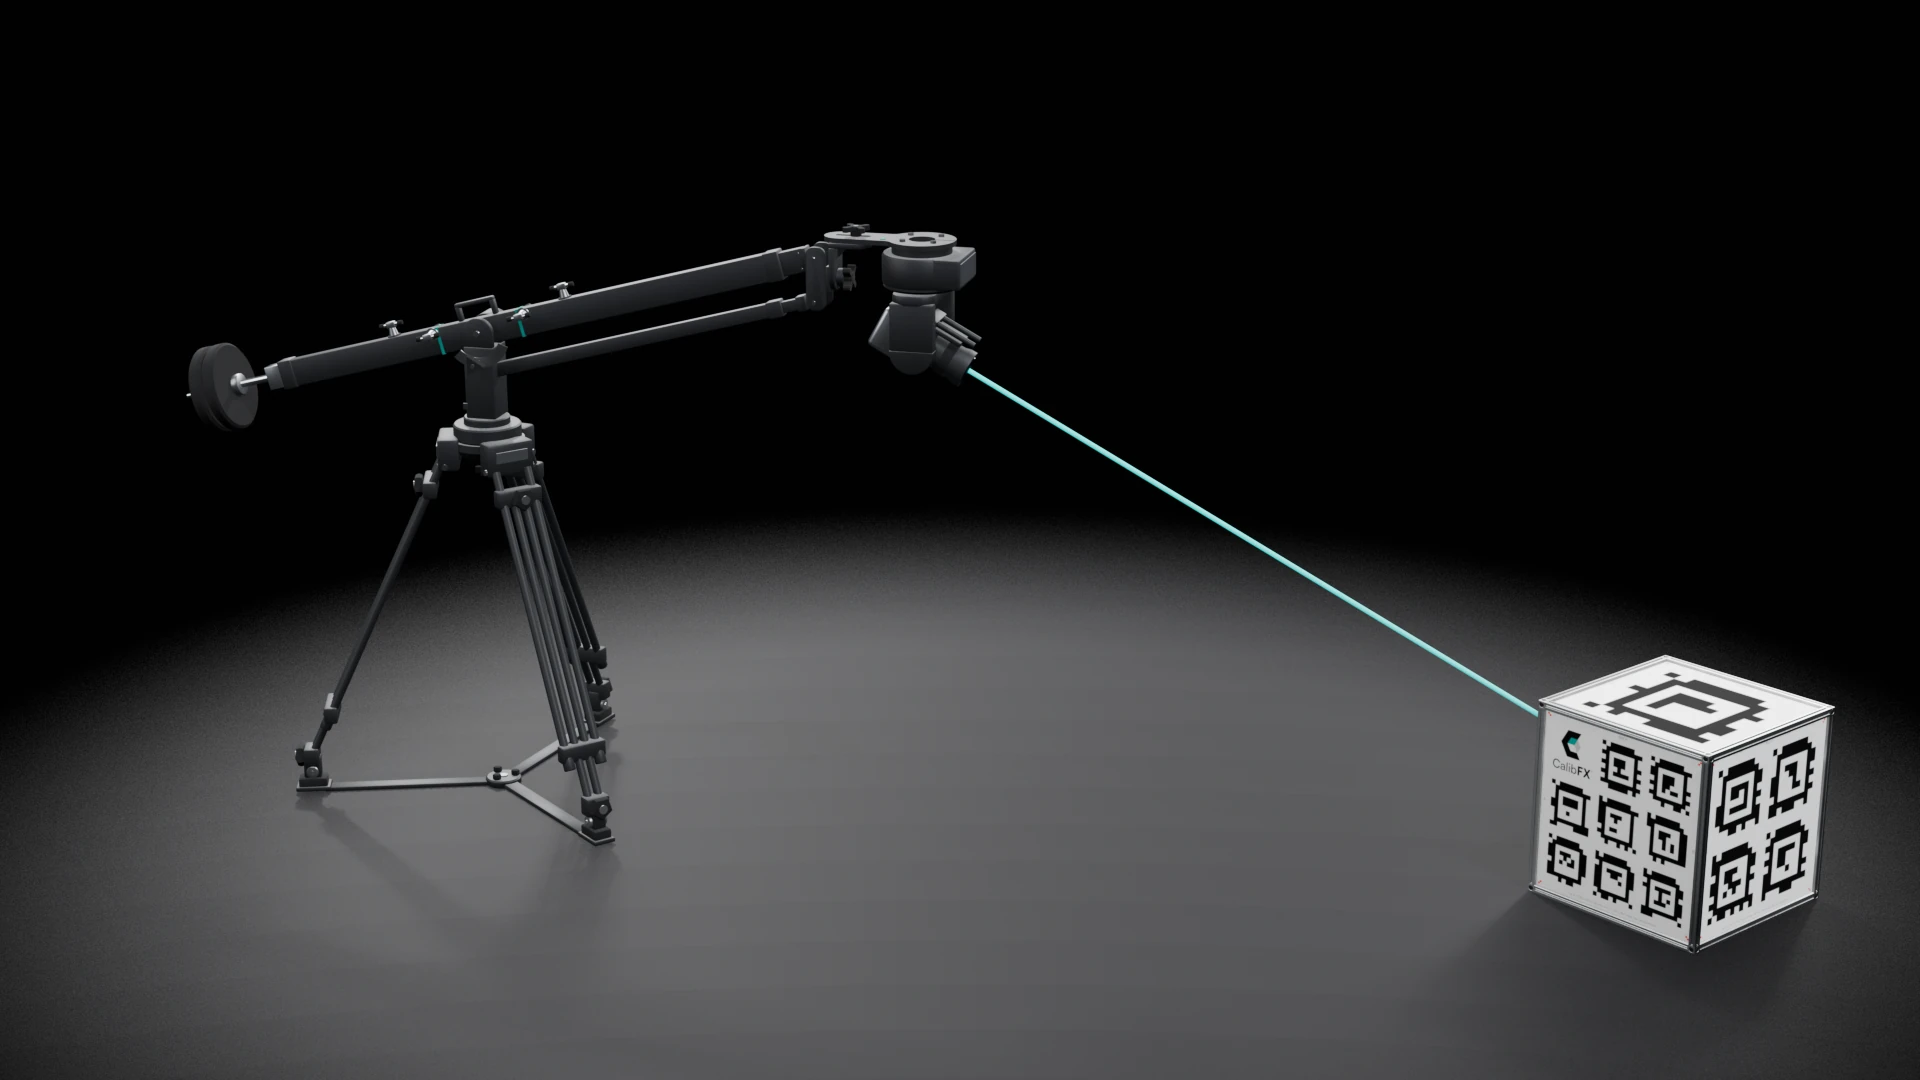
The Sony ILME-FR7 hangs under the arm tip of a Cartoni e-Jibo on a tripod. RigFX reads the jib's pan and tilt from its Cartoni encoders, takes the FR7's own pan, tilt and lens over OpenTrackIO11, and sends the whole camera to the render engine. The e-Jibo + FR7 underslung rig Preset14 builds the chain: you measure two dimensions.
You need
- RigFX Cartoni, with the Cartoni firmware
- a Cartoni e-Jibo with its encoder cable
- a Sony FR7 on the same network, and its mounting plate
- a genlock reference
1. Assembly
Pick up the mounting plate.
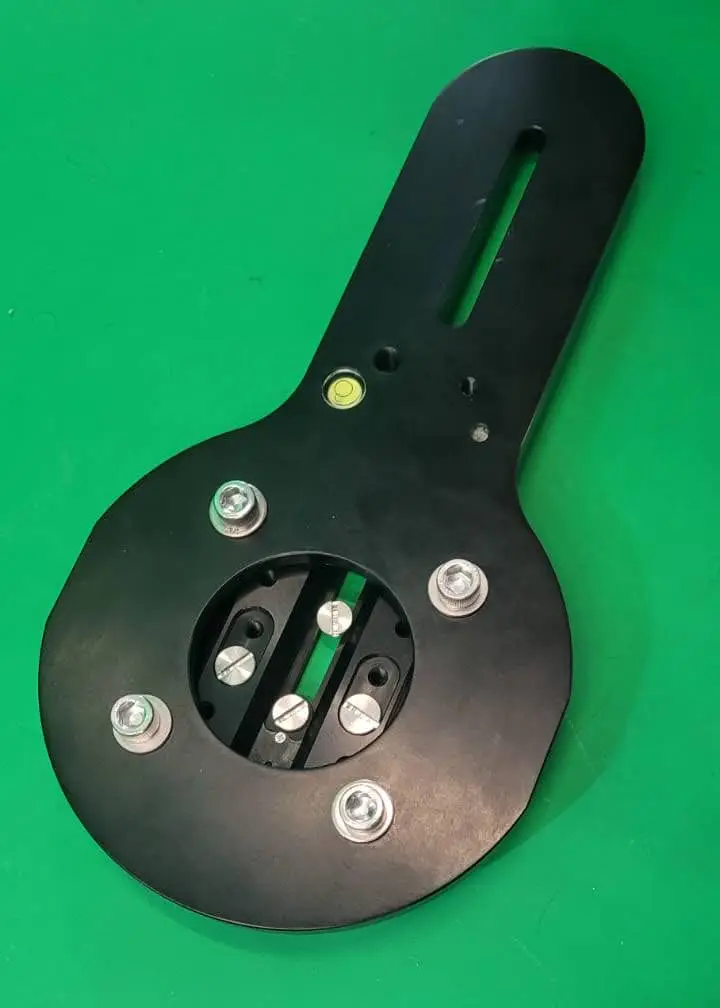
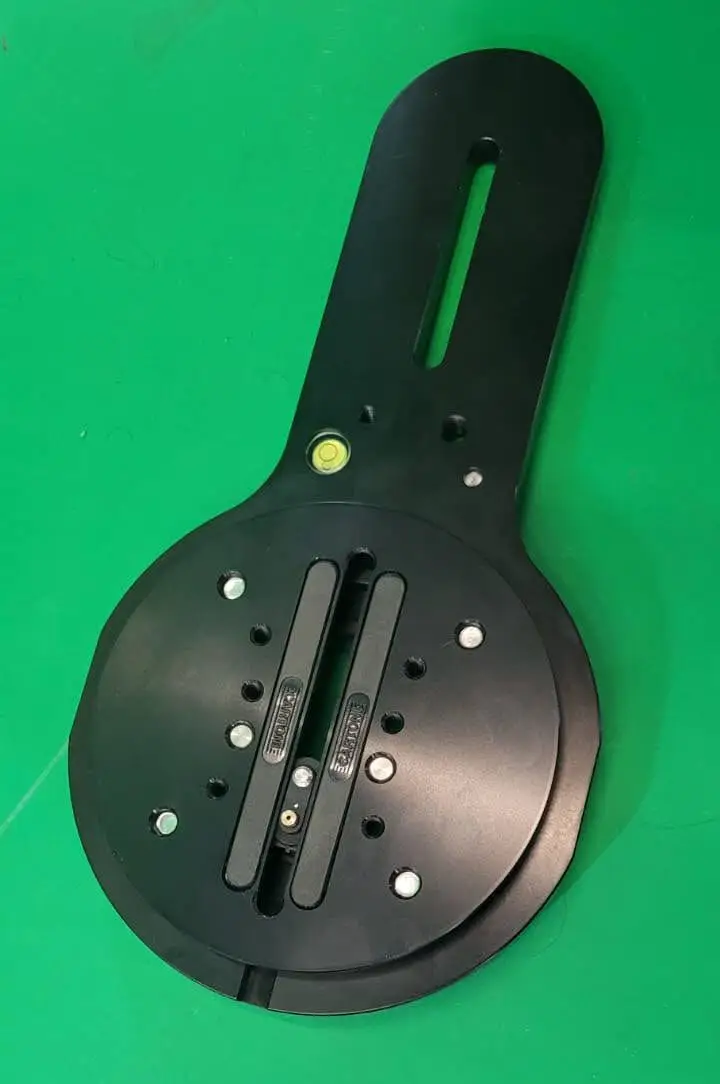
Fasten the mounting plate to the FR7 base with two screws, guided by the alignment pin.
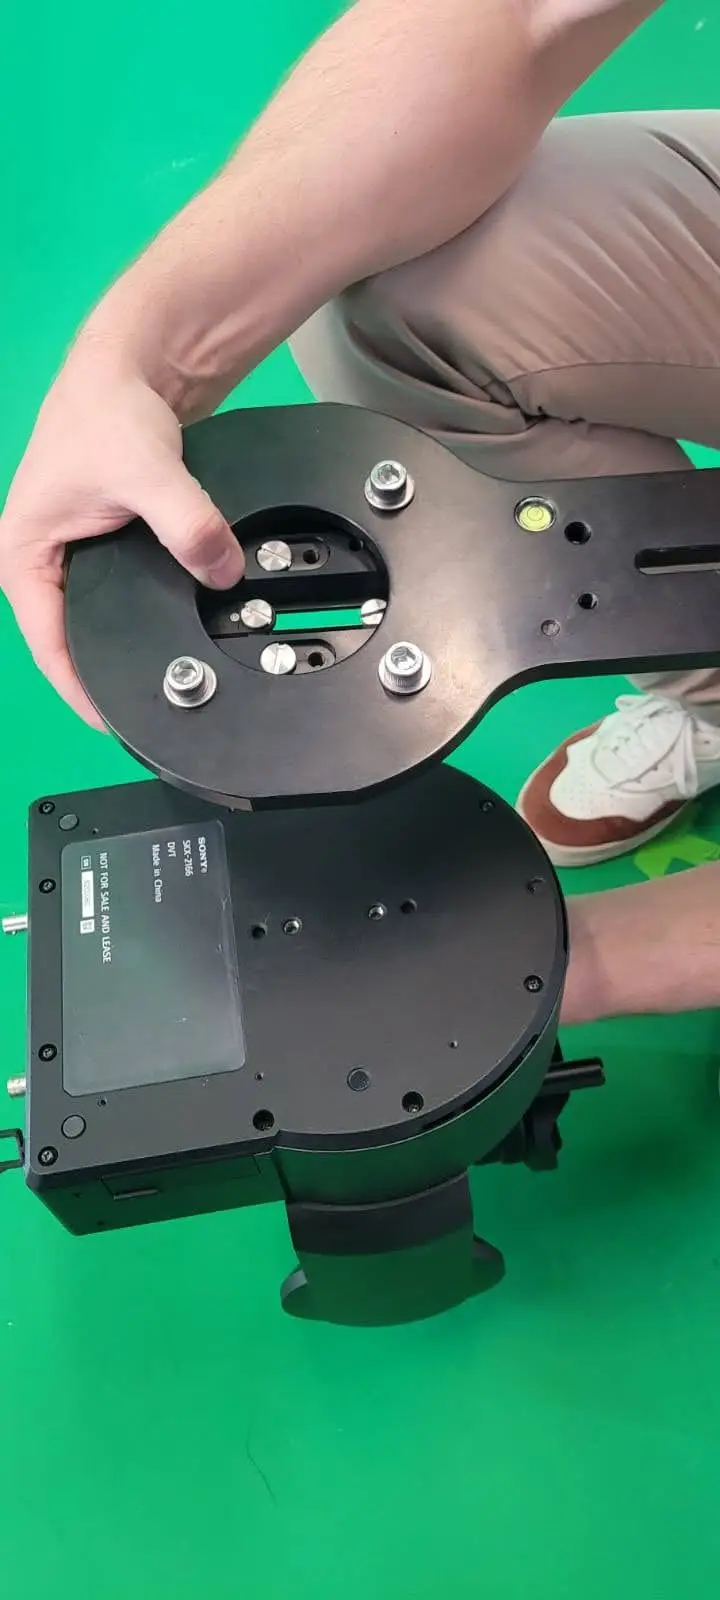
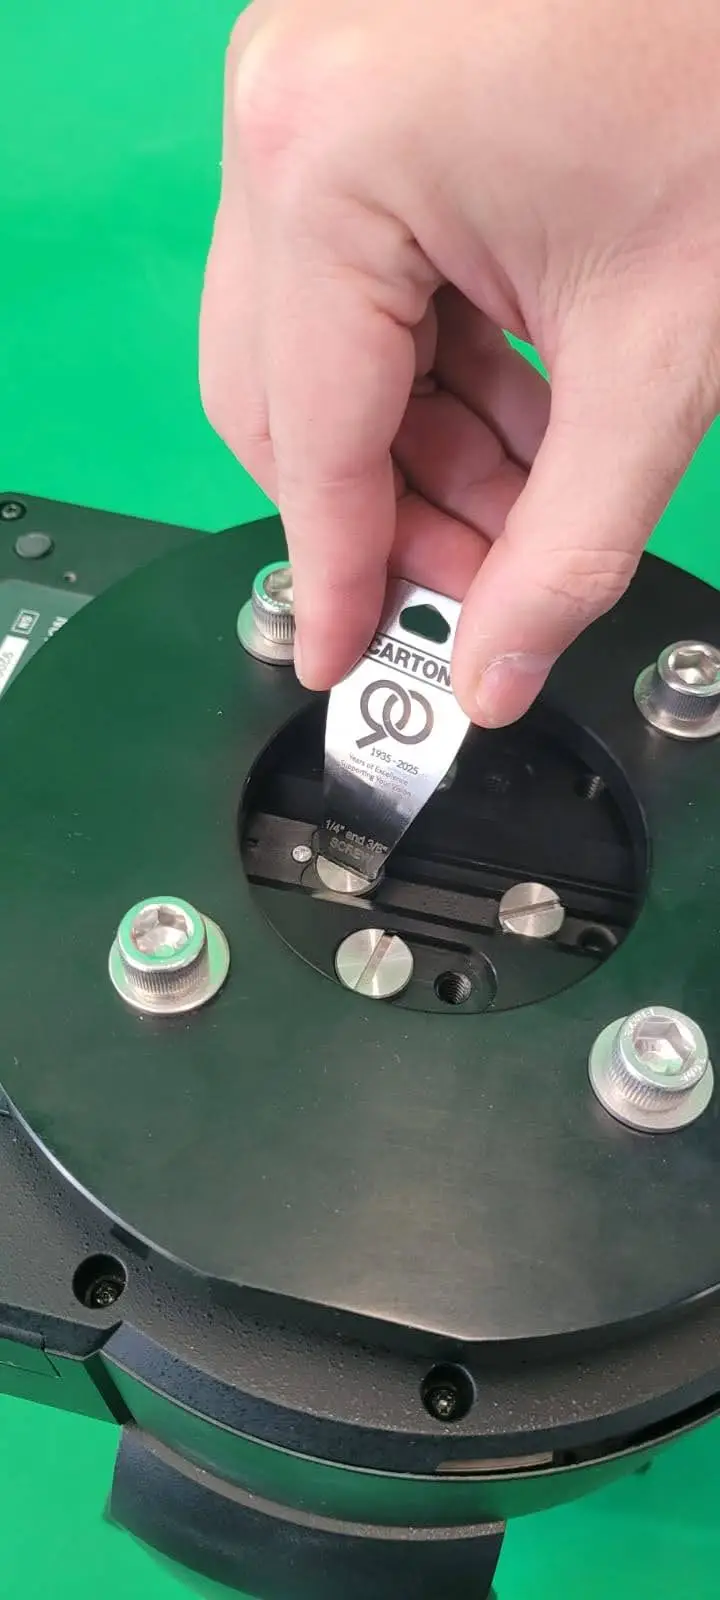
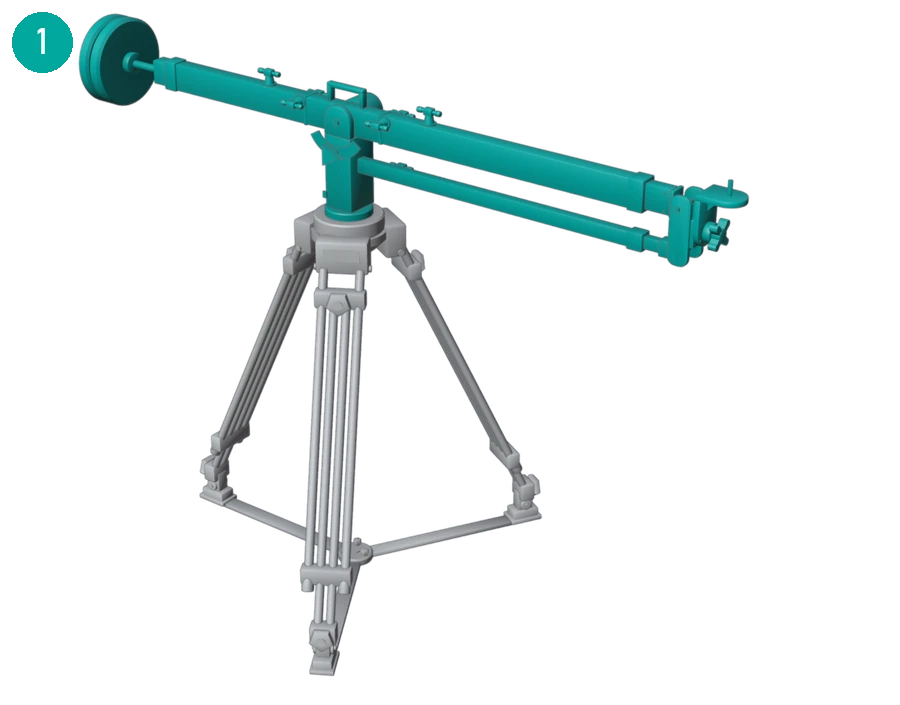
Install the e-Jibo.
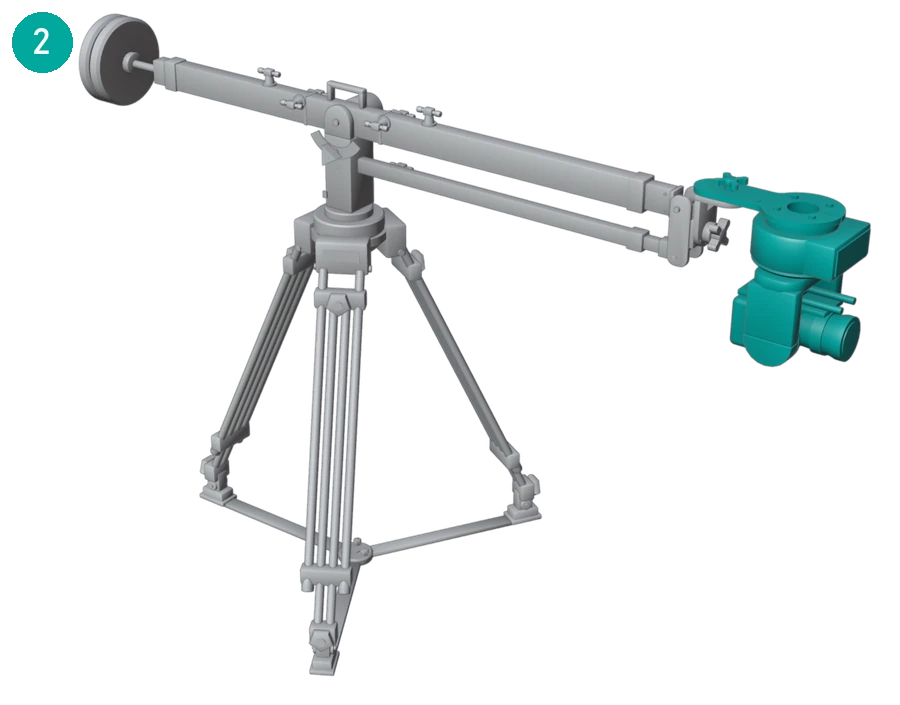
Position the FR7 on the front section of the e-Jibo.
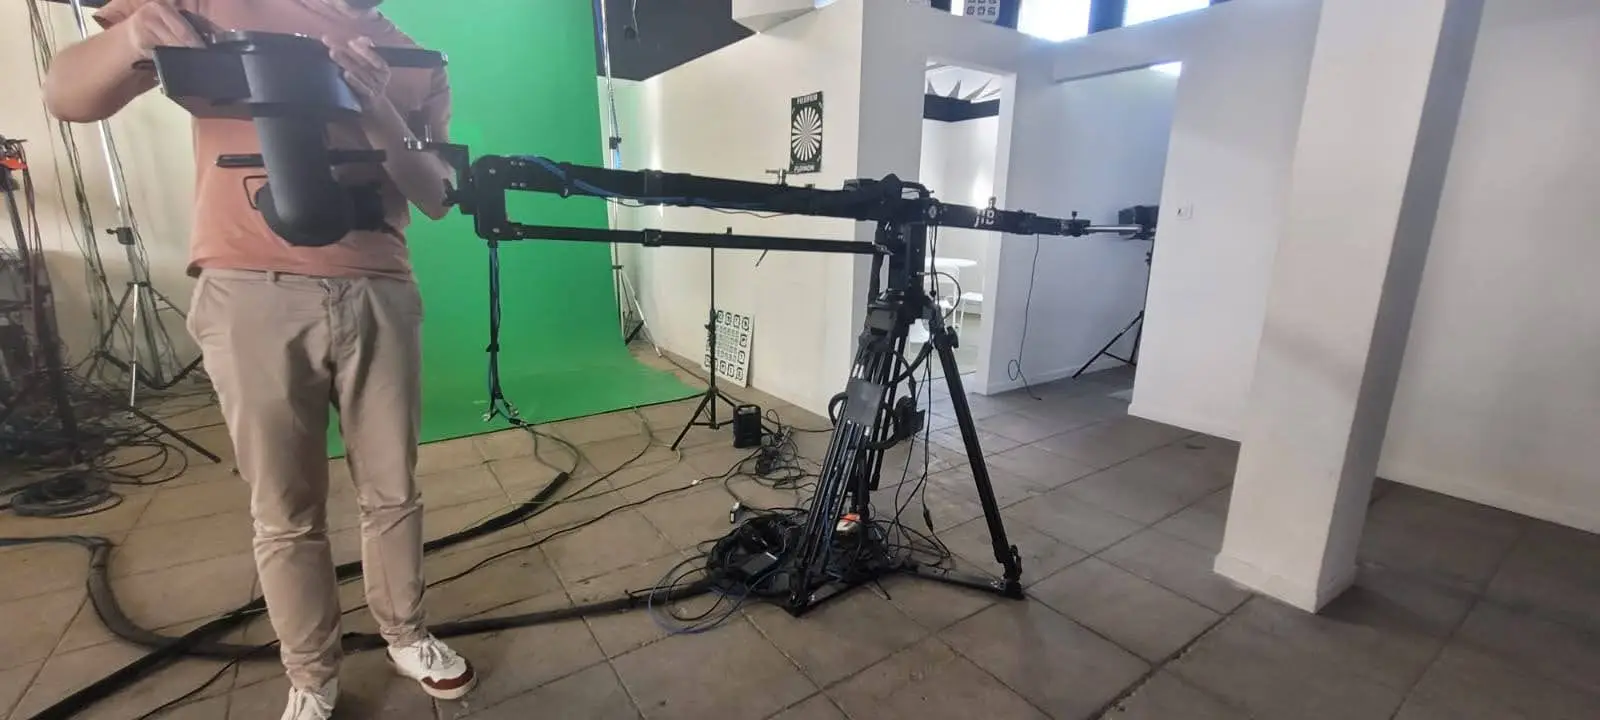
Hand-tighten the knob on the mounting plate.
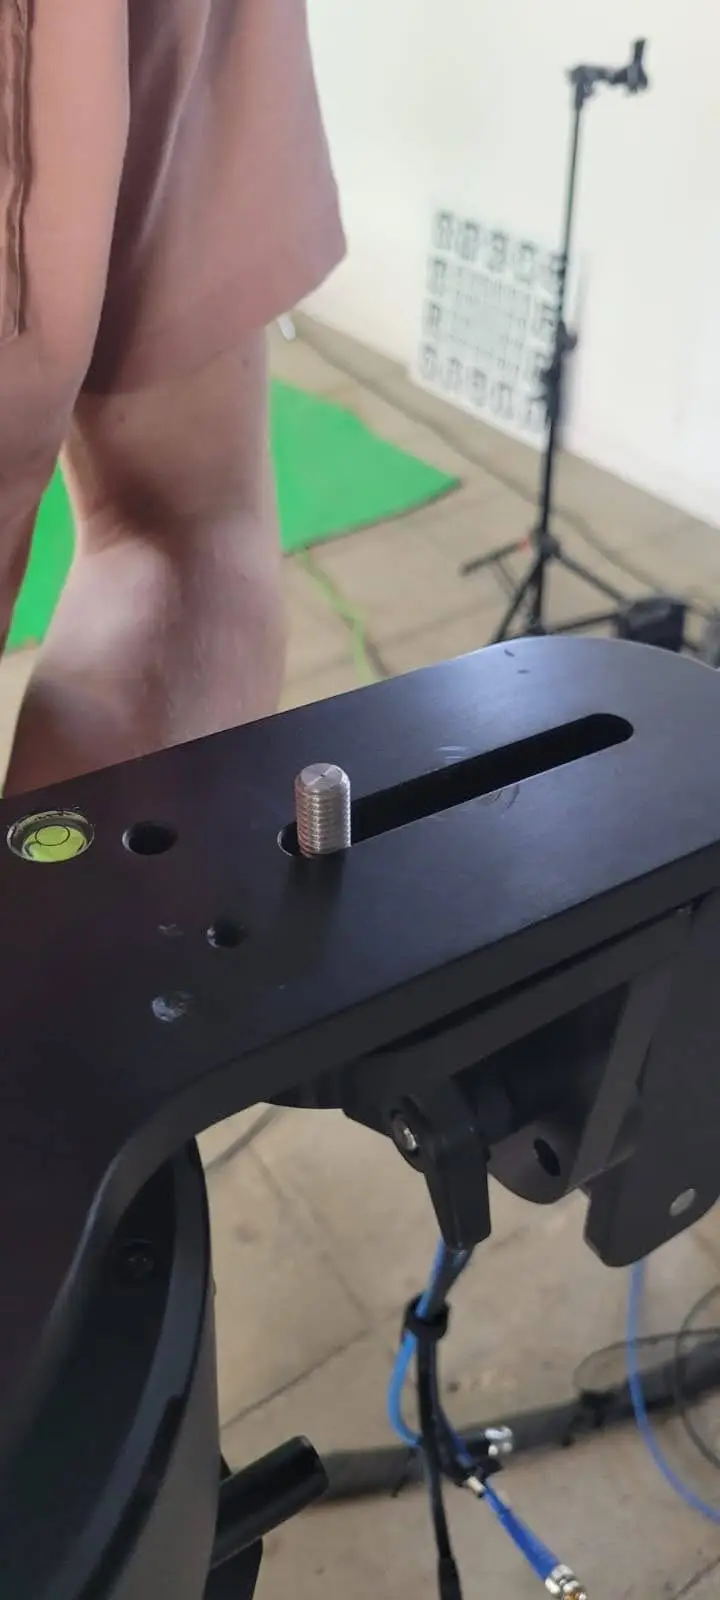
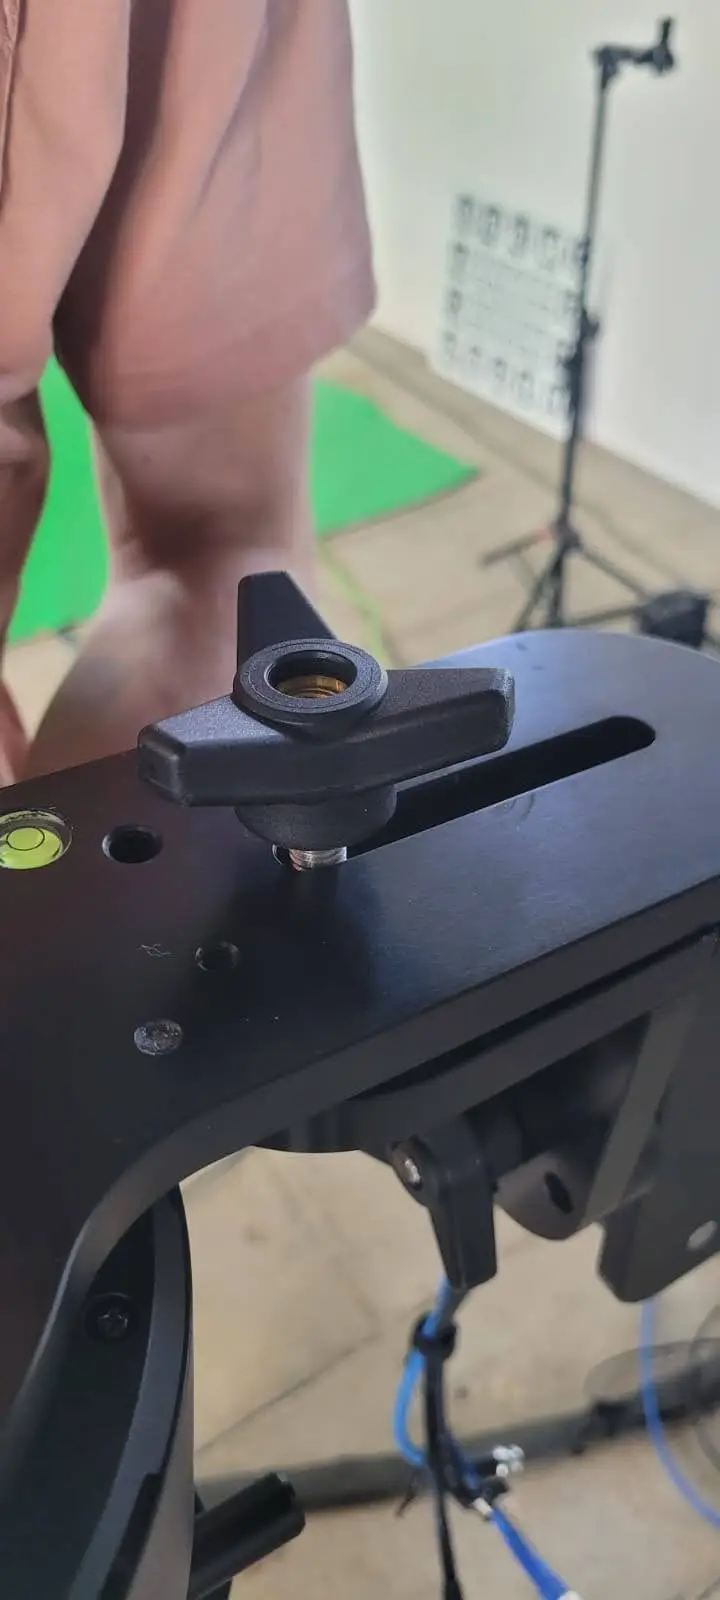
Align the mounting plate with the e-Jibo arm.
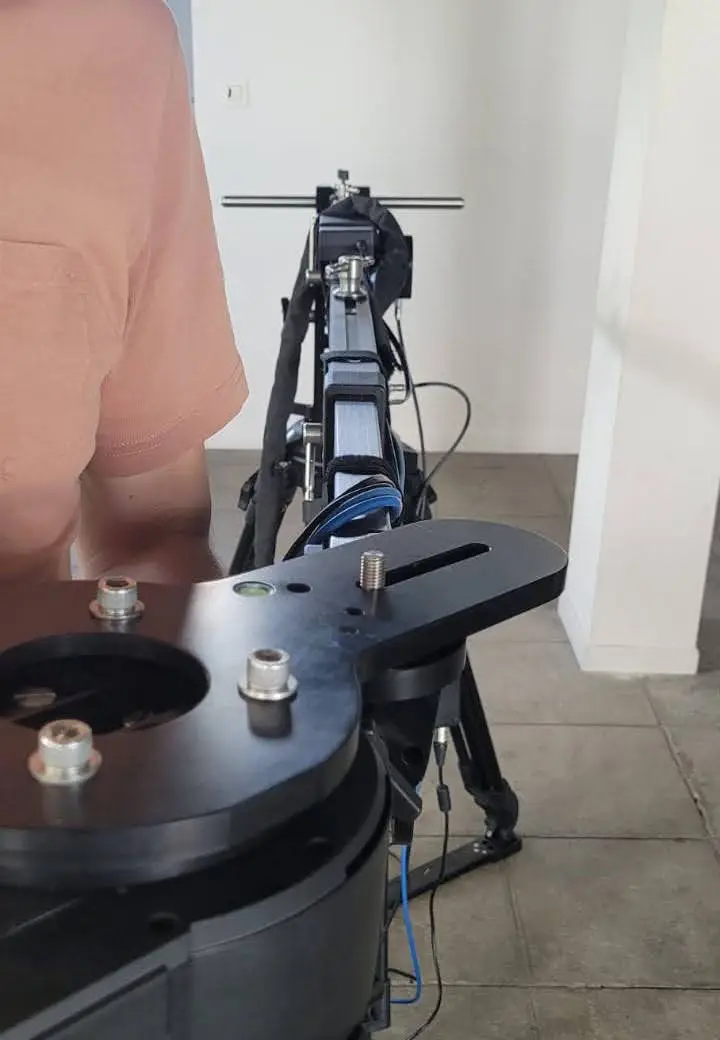
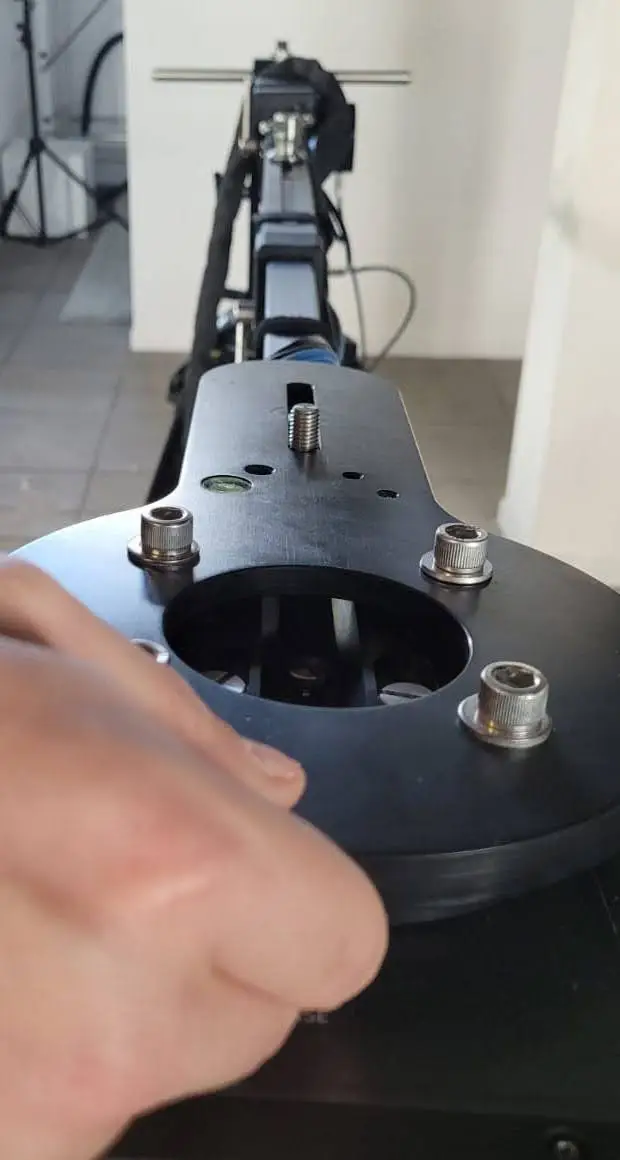
Align the head vertically.
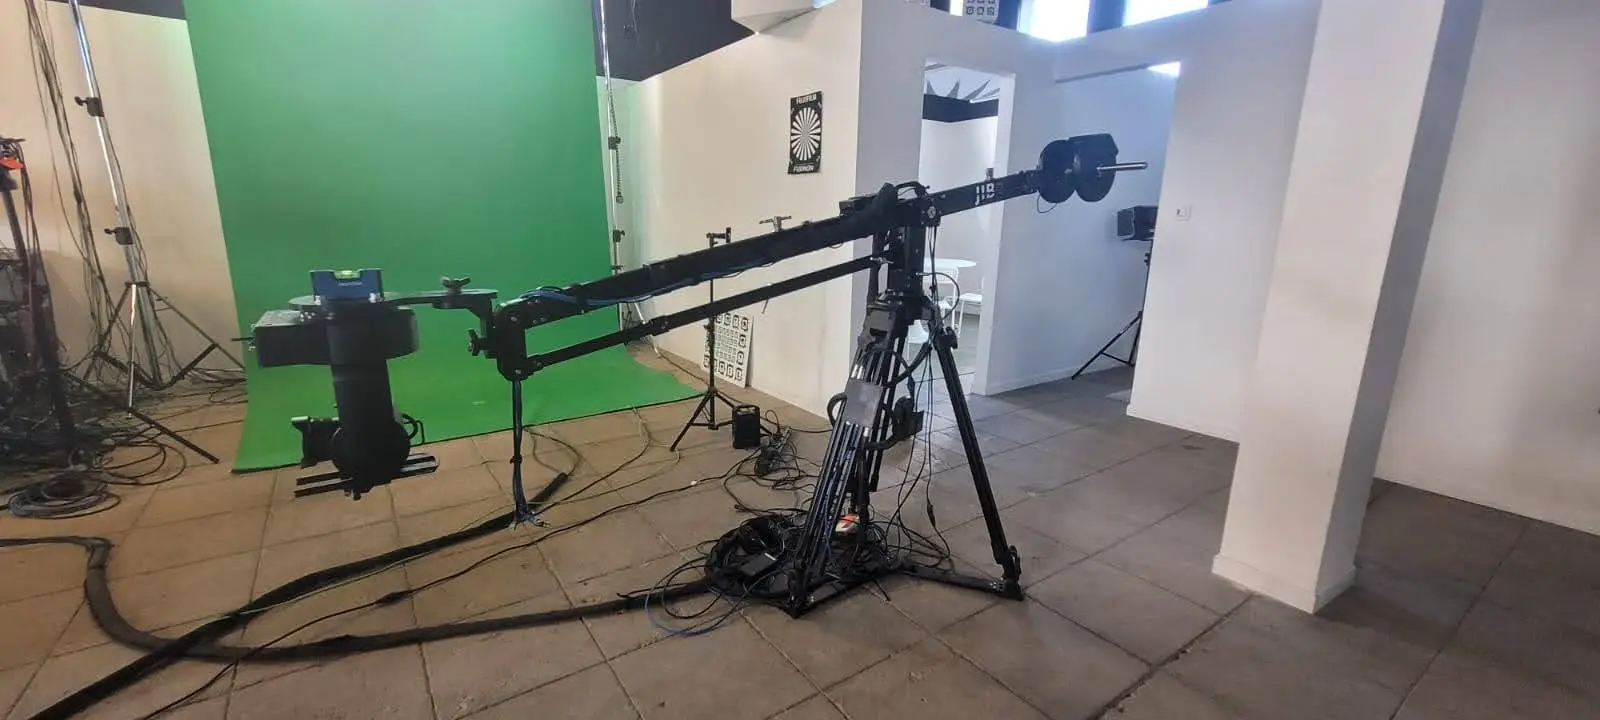
Align the arm vertically.
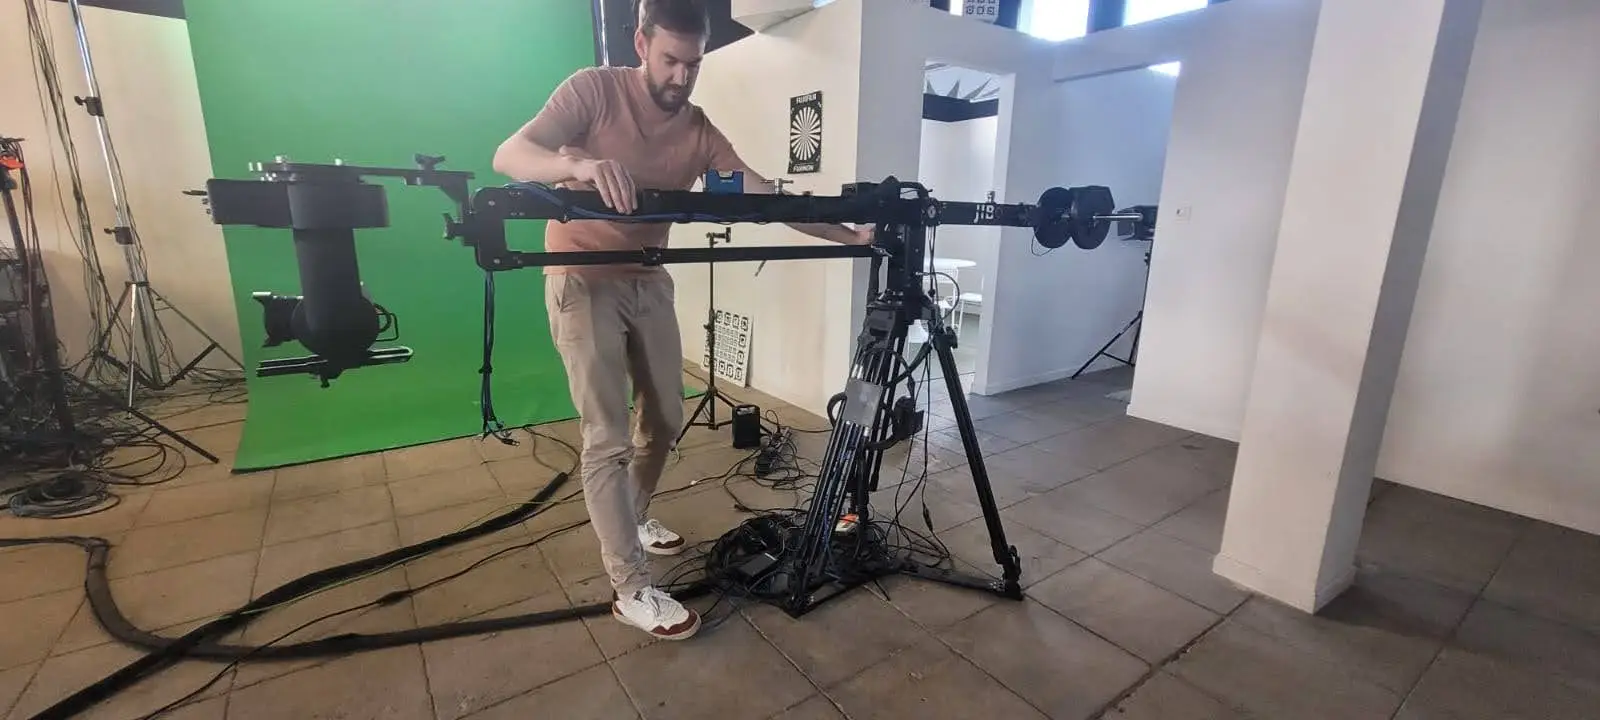
Success
Assembled.
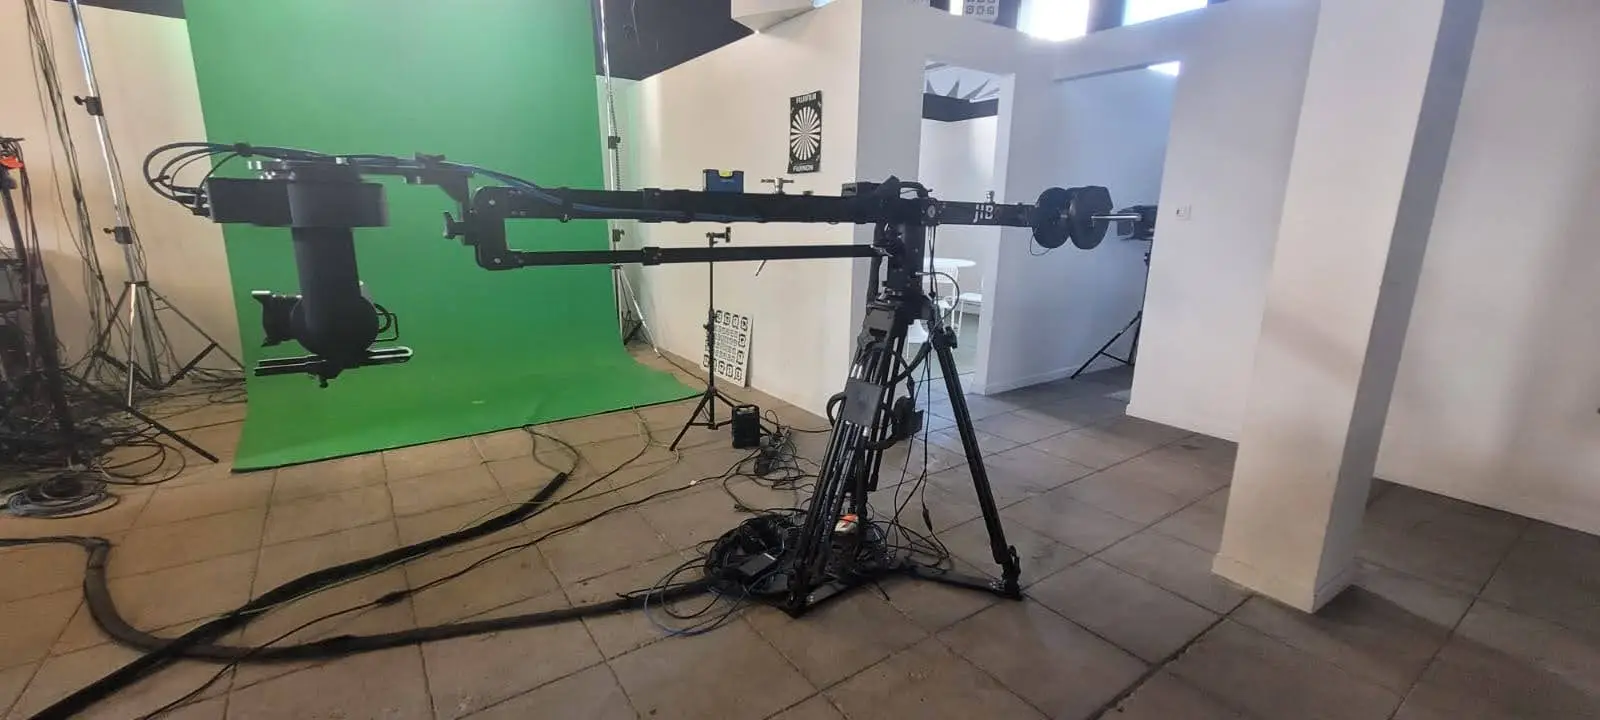
2. What to measure
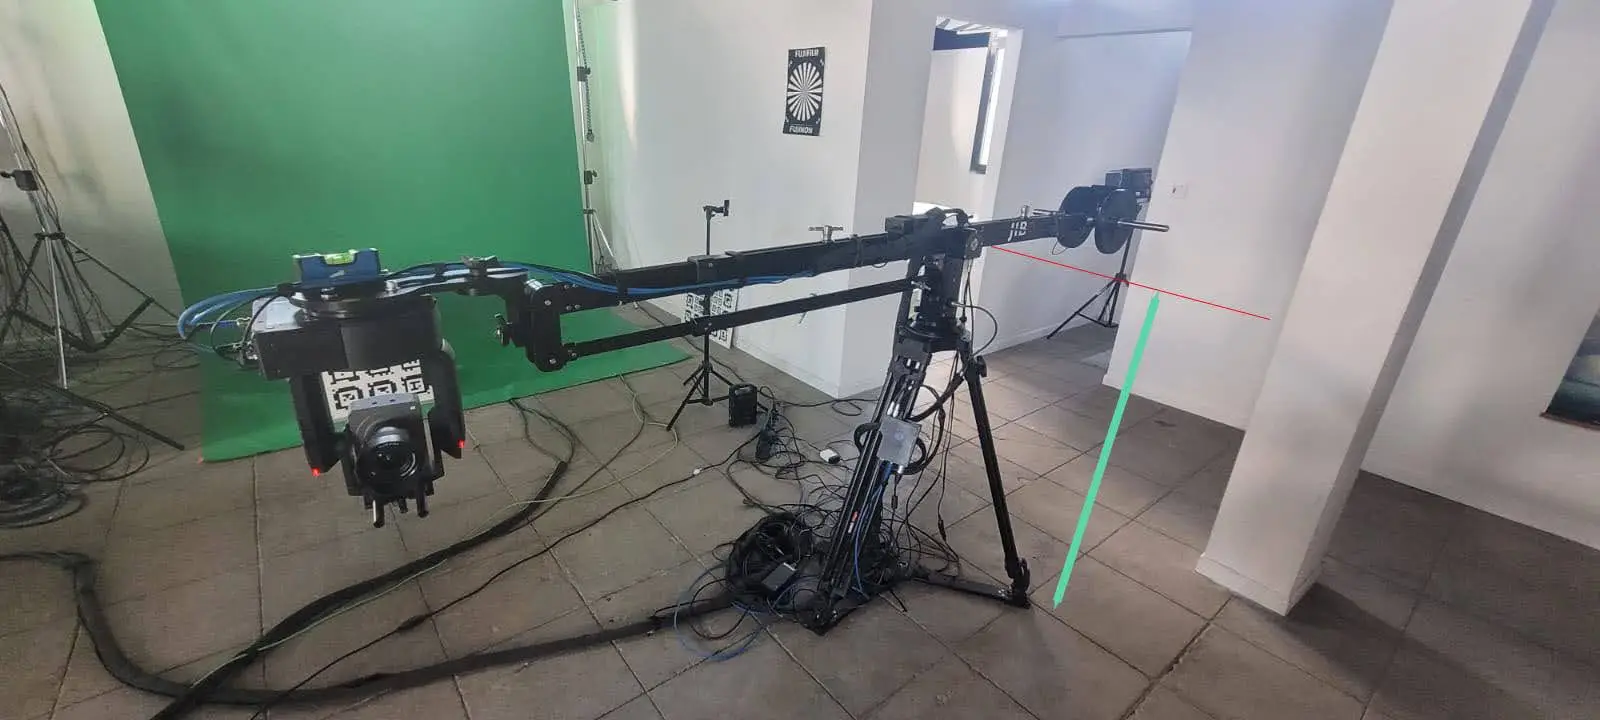
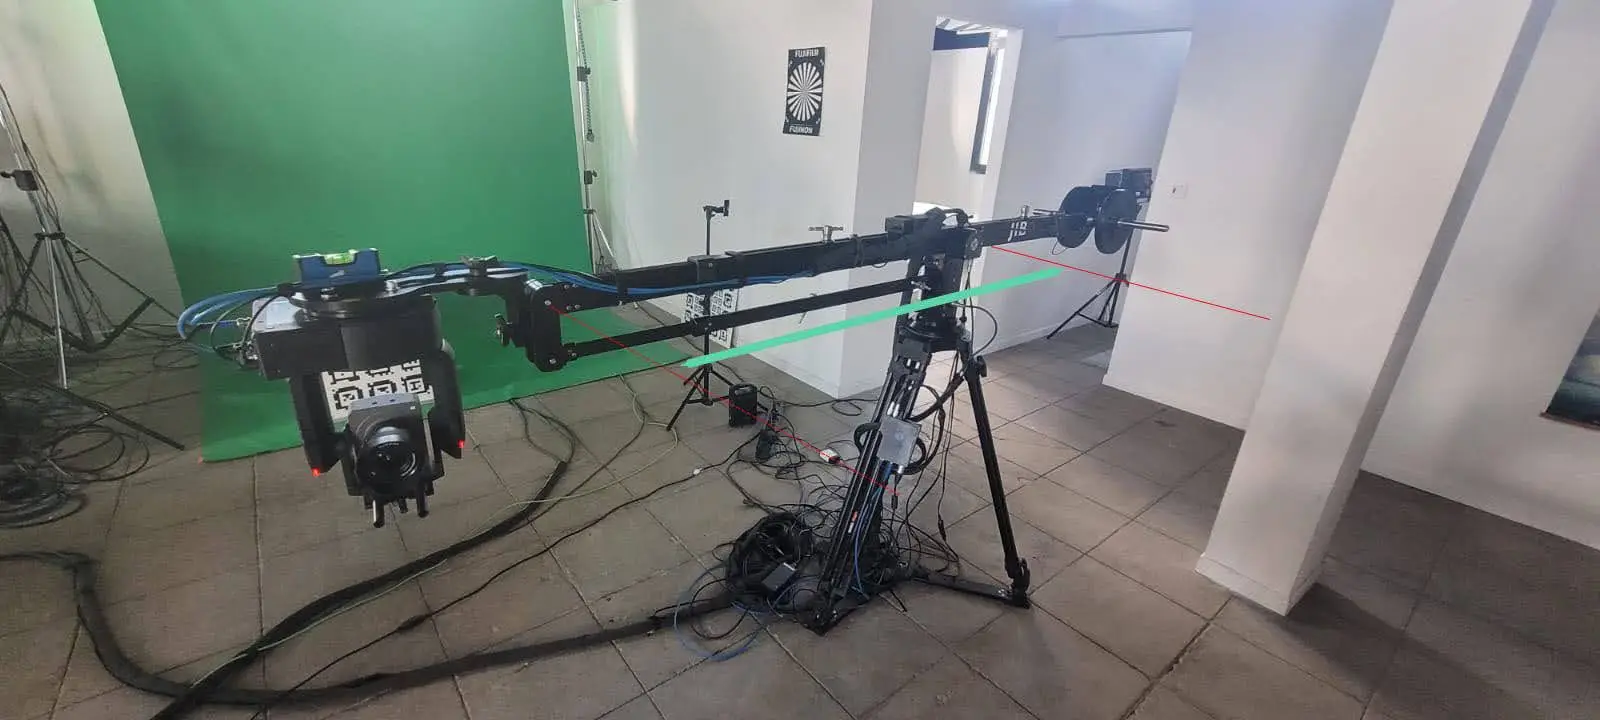
The e-Jibo + FR7 underslung Preset14 takes every other dimension from Cartoni's and Sony's drawings: the jib axle above the bowl, the head plate on the arm tip, the FR7's tilt axis under the plate and its Sensor plane16. Measure only these two on your rig (figure):
1. Tripod height, from the floor to the top of the tripod bowl, where the jib base sits.
2. Arm length, from the jib pivot axle to the arm-tip pin, centre to centre. The arm telescopes: measure it at the length you use.
3. Cabling
^ stream and the render engine on the network](../../../../assets/diagrams/wiring_jib_fr7_underslung.svg)
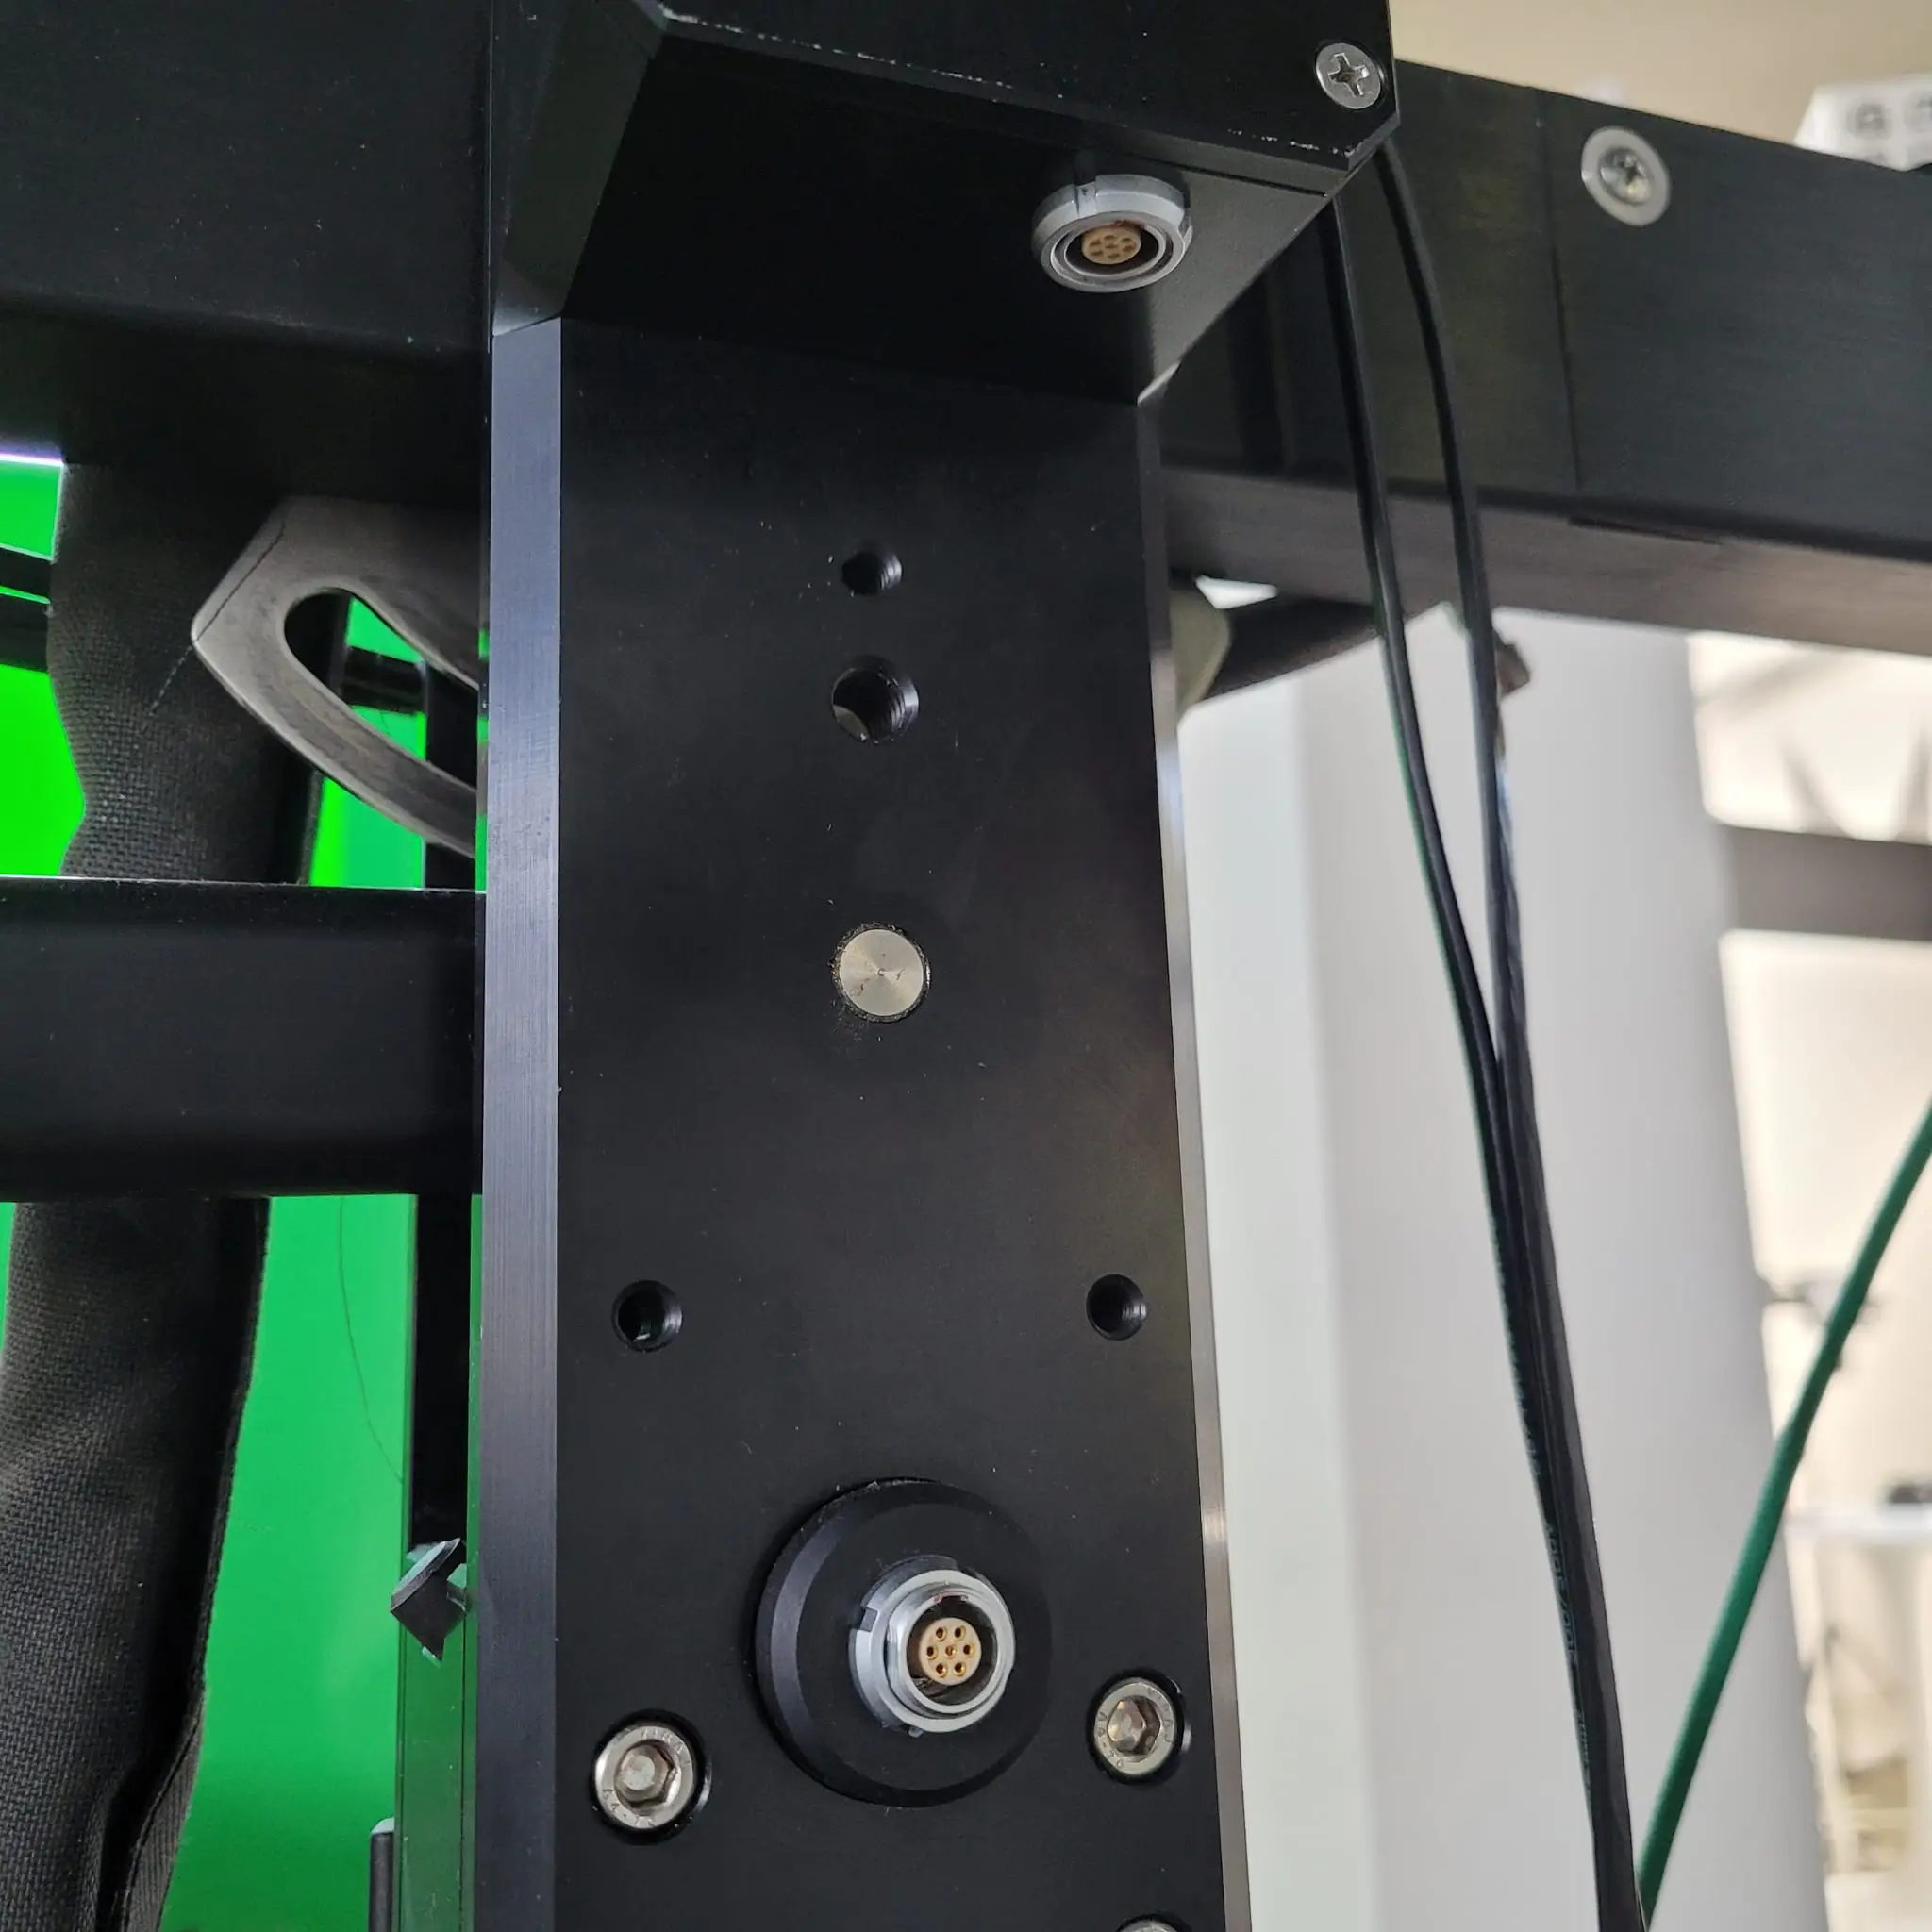
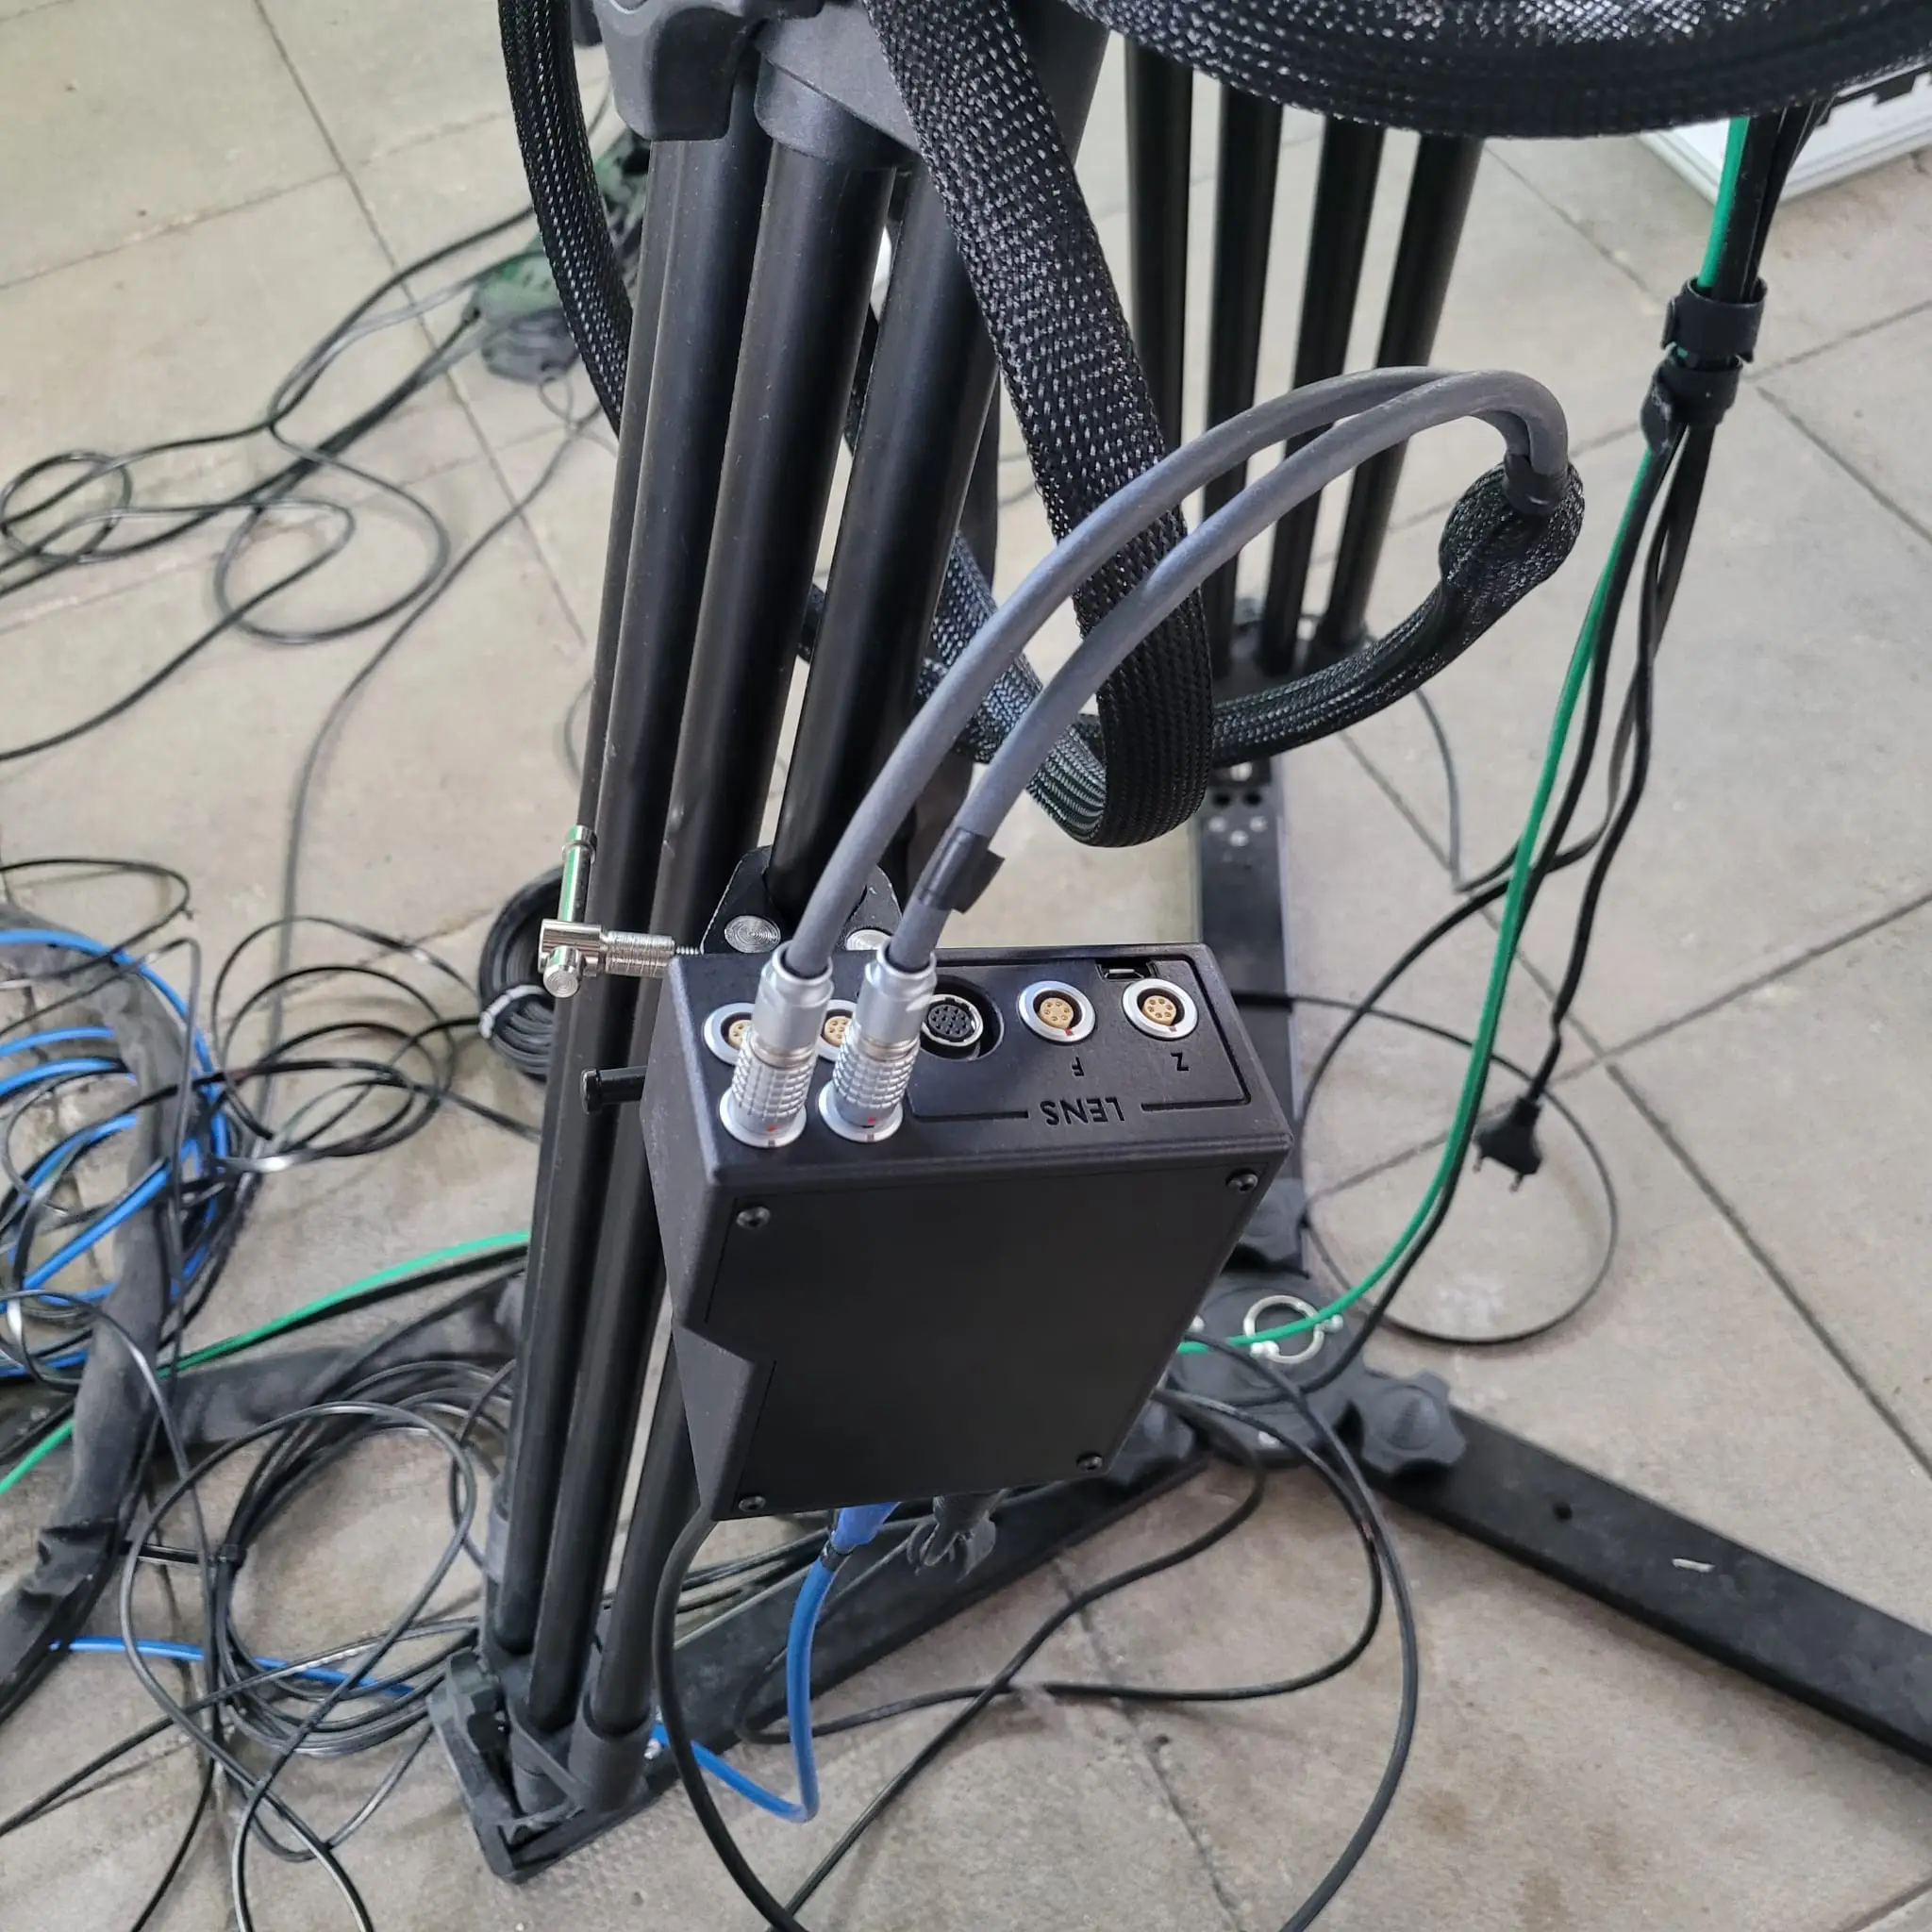
- Plug the e-Jibo's pan and tilt encoder cable into the e-Jibo.
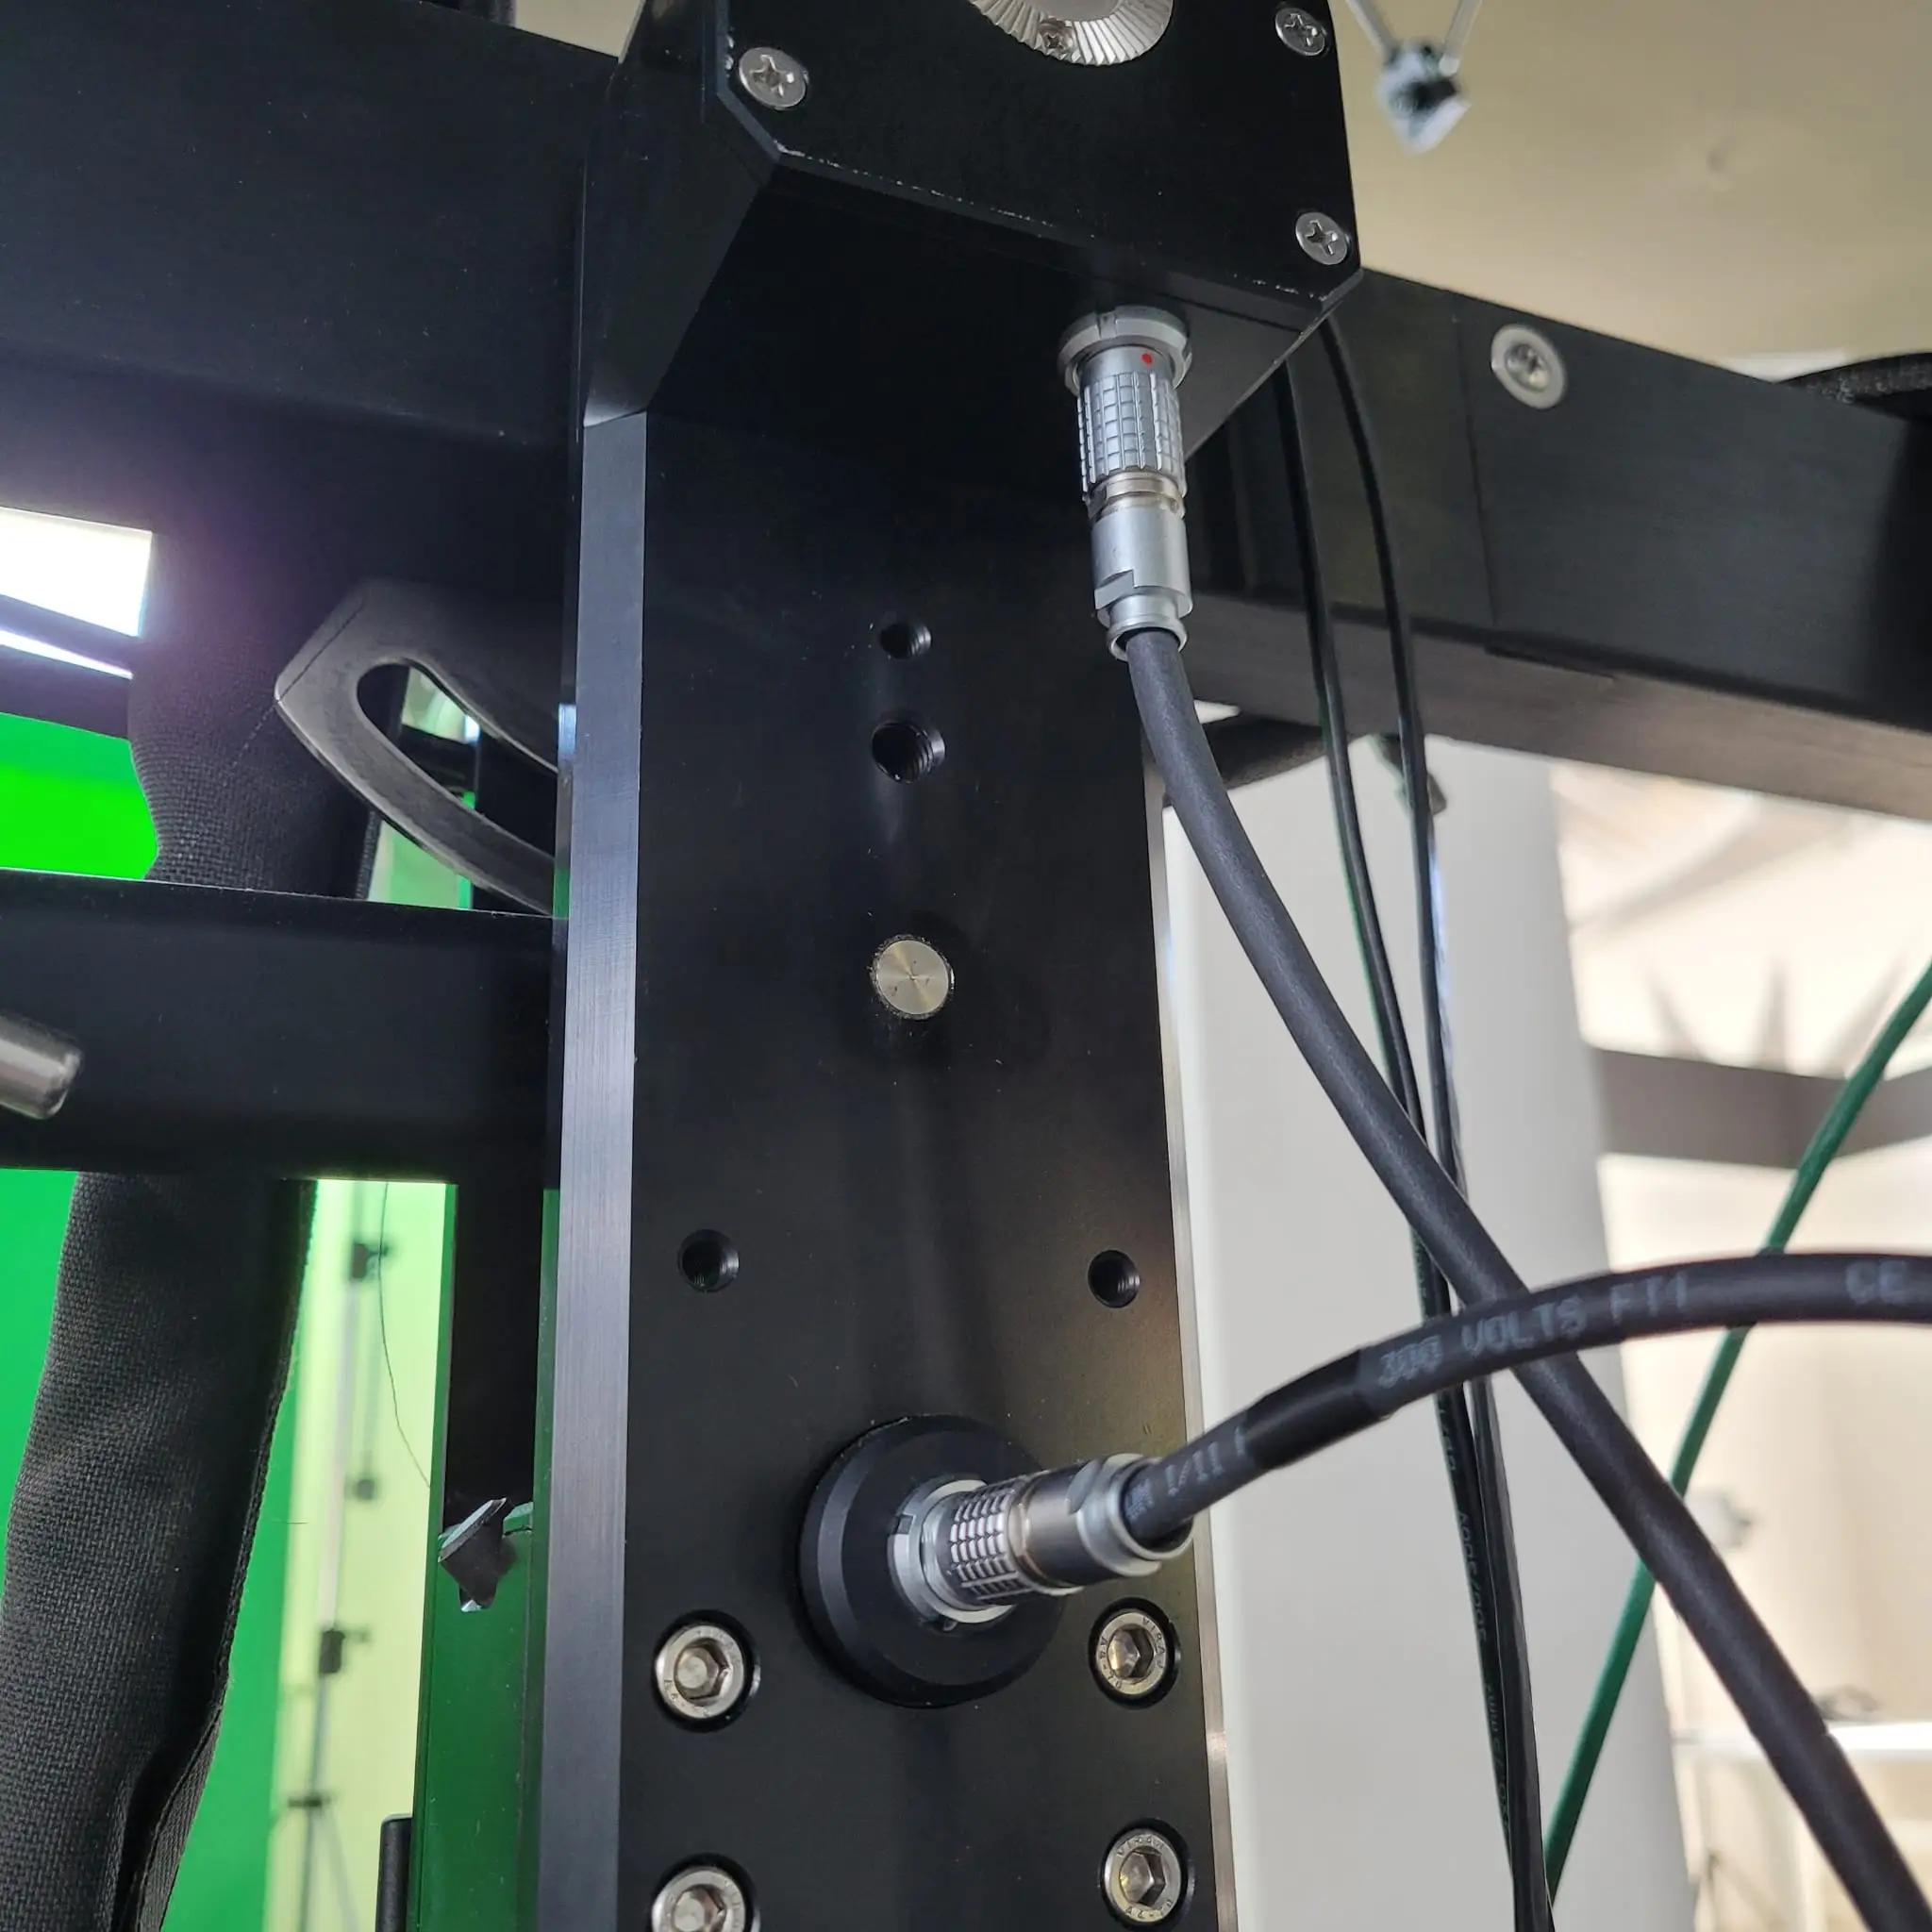
- Plug its other end into the Cartoni encoder inputs 1 (pan) and 2 (tilt) of RigFX Cartoni.
- Connect the FR7 and RigFX to the same network (Network), and the genlock to the RigFX Ref input (Genlock / Sync).
4. Sync
In the web app, Settings → Sync:
- Sync mode: External.
- Target framerate: the studio's frame rate.
- The status under the timecode reads Locked, and the measured FPS matches the target.
^ and the Phase View](../../../../assets/screenshots/settings_sync.webp)
5. Cartoni source: zero the jib
On the rig:
- Turn the arm to the direction you want as pan zero, one easy to find again, such as parallel to the studio's main wall.
- Level the arm, perfectly horizontal, and lock it.
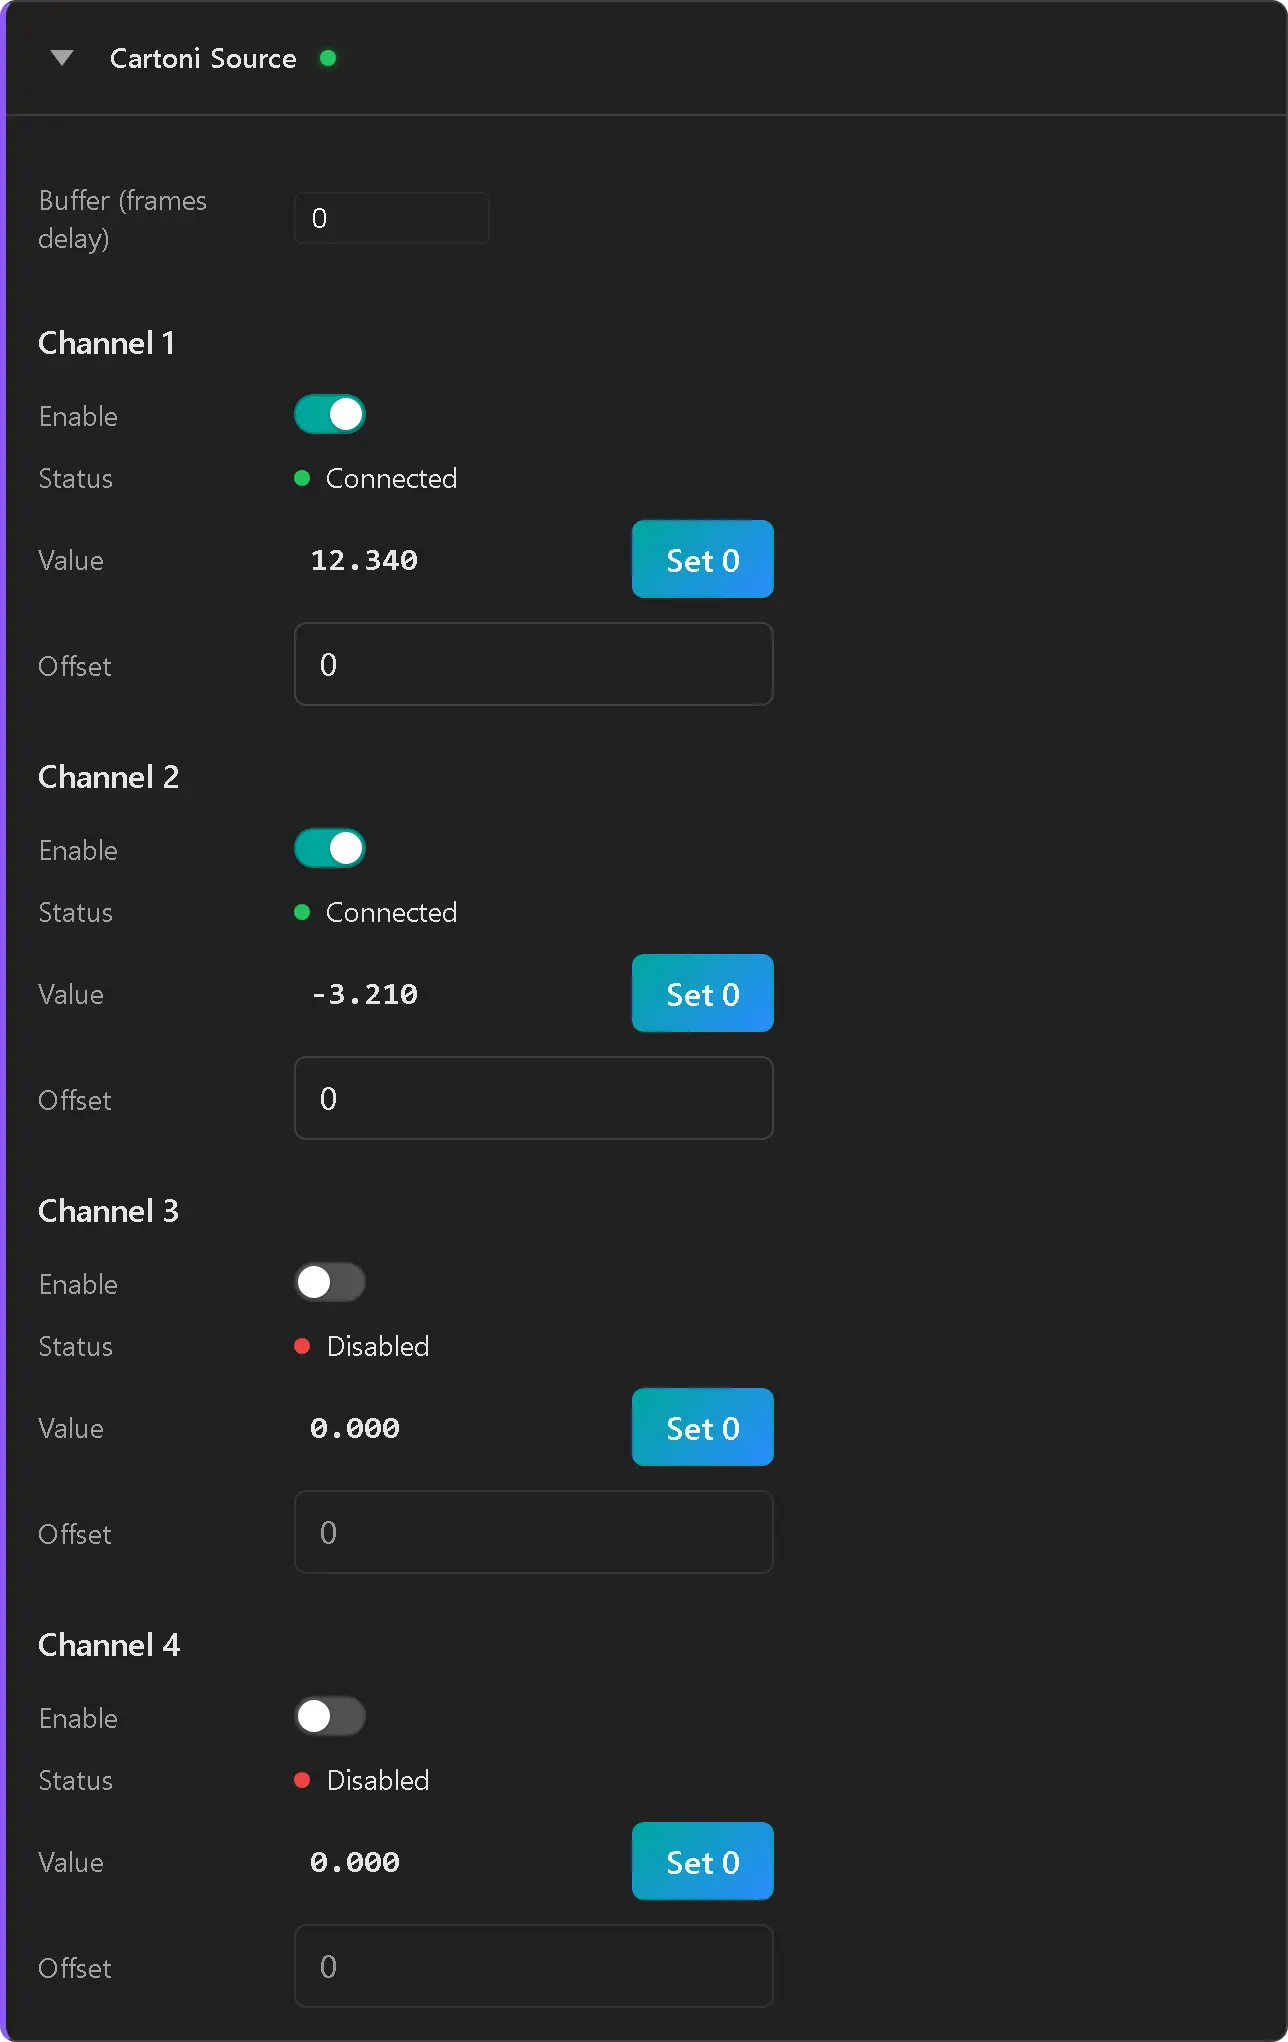
In Settings → Source → Cartoni:
- Enable channels 1 and 2 only.
- Click Set 0 on channels 1 and 2: each reads zero at this position.
Success
Unlock the arm: it is calibrated.
6. OpenTrackIO source: the FR7
On the FR7:
- Set it to its ceiling (upside-down) installation mode: it then corrects its own pan, tilt and image, and the preset needs no correction.
- Send its OpenTrackIO11 stream to the RigFX address and port. Leave its own position offsets at zero: the chain in RigFX places it.
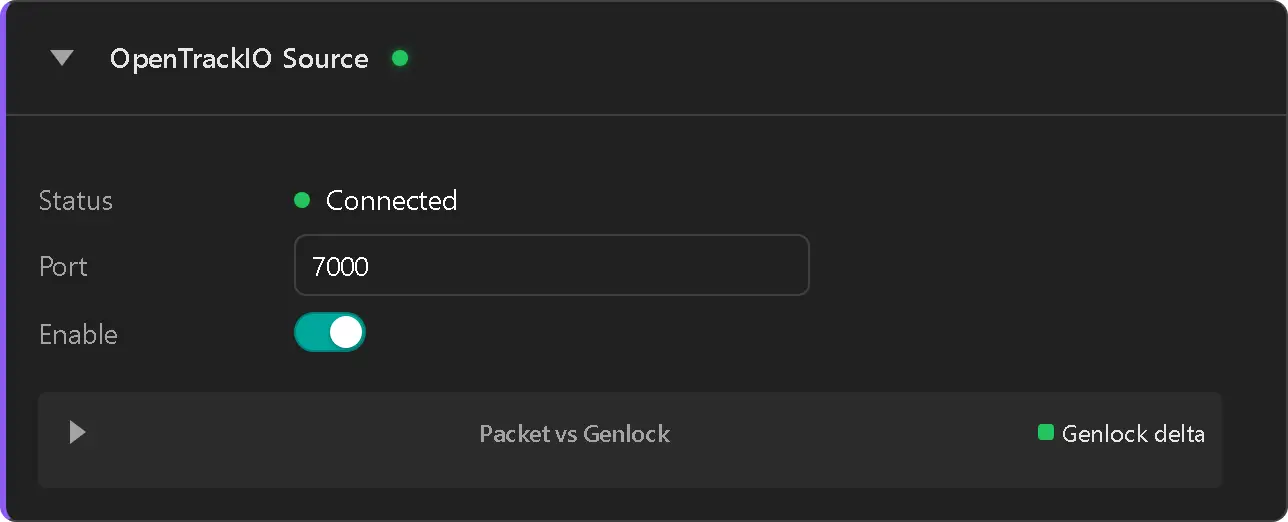
In Settings → Source → OpenTrackIO:
- Set the reception port and enable the source.
- The Timing row shows the packet rate and when packets arrive after the sync pulse. Phase view › opens the Phase View: packets drawn orange arrive after the Phase offset12, so raise the Phase Offset in Settings → Sync until they land before it.
7. Rig: load the preset
In Settings → Rig, click Presets and load e-Jibo + FR7 underslung (Rig presets). It builds the whole chain, already bound to the Cartoni channels and the FR7 (the nodes and what each one sets).
^ loaded: its nodes on the left, the rig in the 3D view on the right](./images/rig_preset.webp)
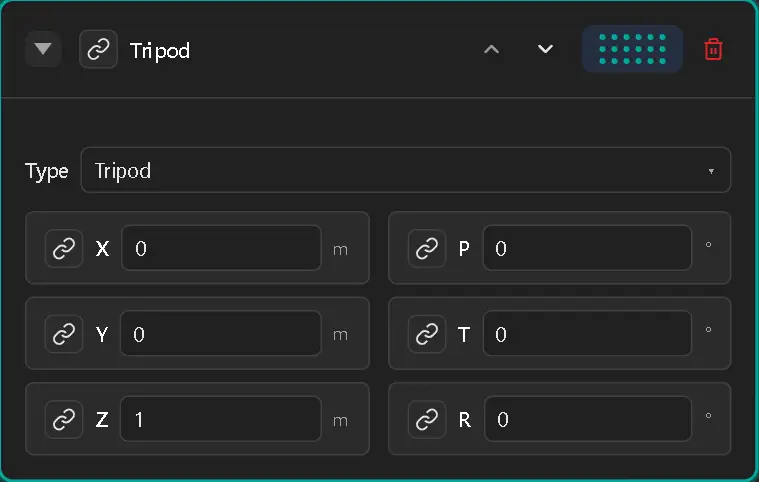
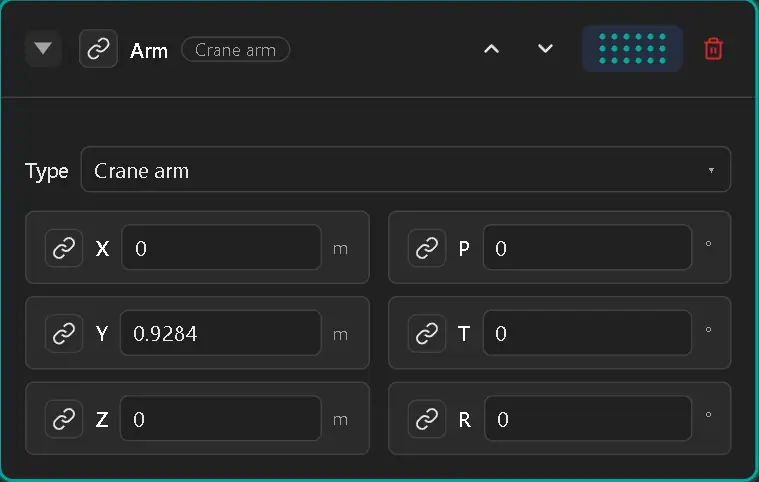
Enter your two measurements on the Tripod card (Z) and the Arm card (Y):
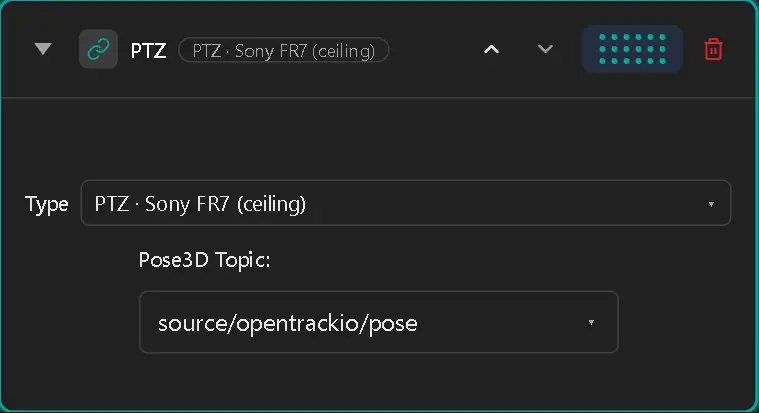
The PTZ card takes the FR7's whole pose from OpenTrackIO11: nothing to set.
The rest of the chain is set by the Preset14. The Studio offset17 is not part of the preset: it places the rig in your studio, and a lineup tool such as CalibFX Lineup fills it (see step 9).
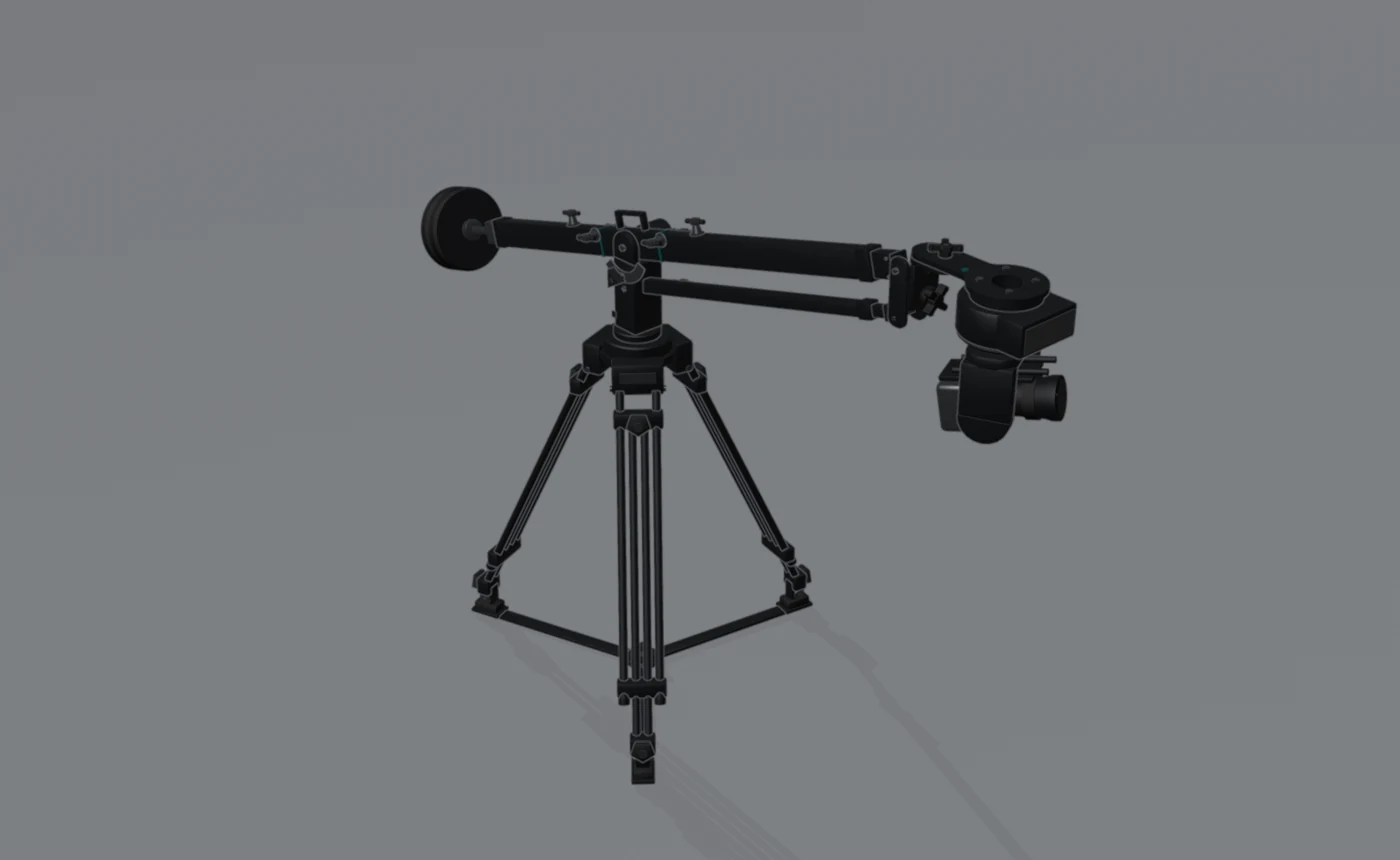
The web app's 3D view now moves with the rig, as here:
Check the directions
Swing the arm left and raise it, then pan and tilt the FR7: the 3D view must follow the same way. If an axis turns the wrong way, tick Negate on that field of its node card.
8. Lens
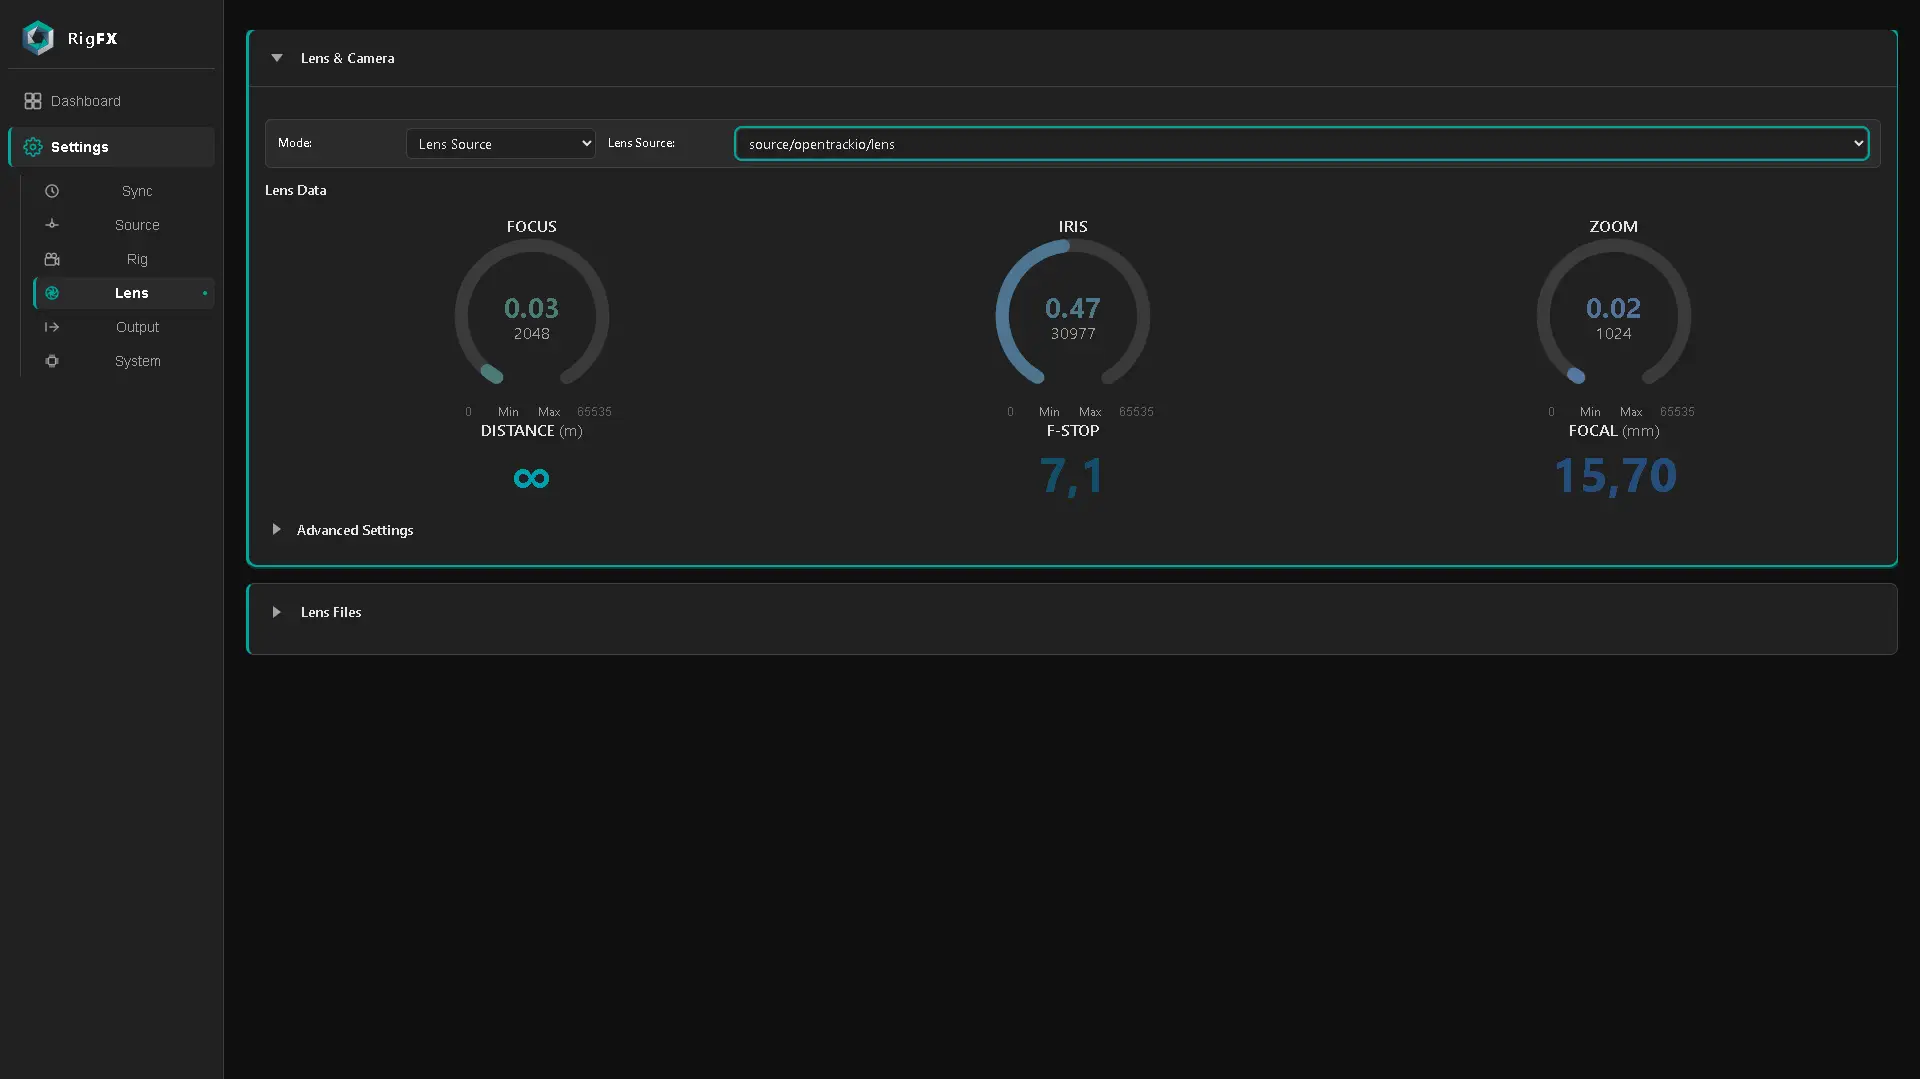
The FR7 sends its calibrated lens in its OpenTrackIO11 stream (Pipeline 3). In Settings → Lens:
- Mode: Lens Source.
- Source: OpenTrackIO11.
9. Output
In Settings → Output, on one destination:
- Protocol: OpenTrackIO11 (it carries the FR7's lens).
- IP and Port: the render engine's.
- Enable it.
Perfect tracking with CalibFX Lineup
Point the camera at the CalibFX cube and let CalibFX Lineup finish the job: from what the camera sees, it solves the Studio offset17, the sensor offset and every node of the chain in between (tripod height, arm length, head offsets), so the virtual camera sits exactly on the real one, without a tape measure.
On an OpenTrackIO11 output, tick Chain transforms: Lineup then receives each node of the rig (Output → OpenTrackIO options).
^ options open](../../../../assets/screenshots/output_opentrackio_options.webp)